Publications
Generated from our BibTeX file. Members of the group are shown in bold.
All
2026
Dual-Force: Enhanced Offline Diversity Maximization under Imitation Constraints
arXiv preprint
·
2026
Differentiable Simulation of Hard Contacts with Soft Gradients for Learning and Control
The Fourteenth International Conference on Learning Representations
·
2026
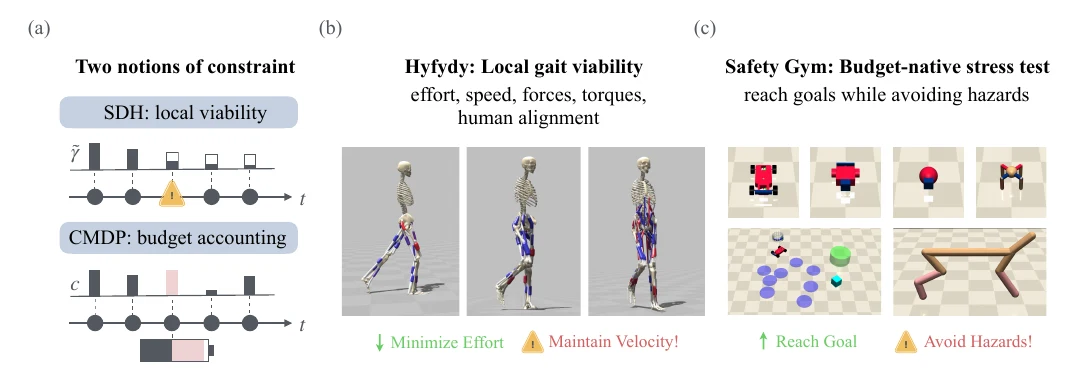
Stochastic Decision Horizons for Survival-Based Constrained Reinforcement Learning
arXiv preprint
·
2026
2025
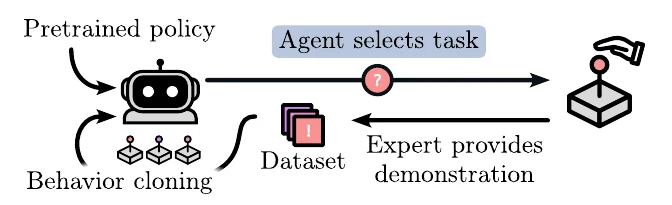
Active Fine-Tuning of Multi-Task Policies
International Conference on Machine Learning (ICML)
·
2025
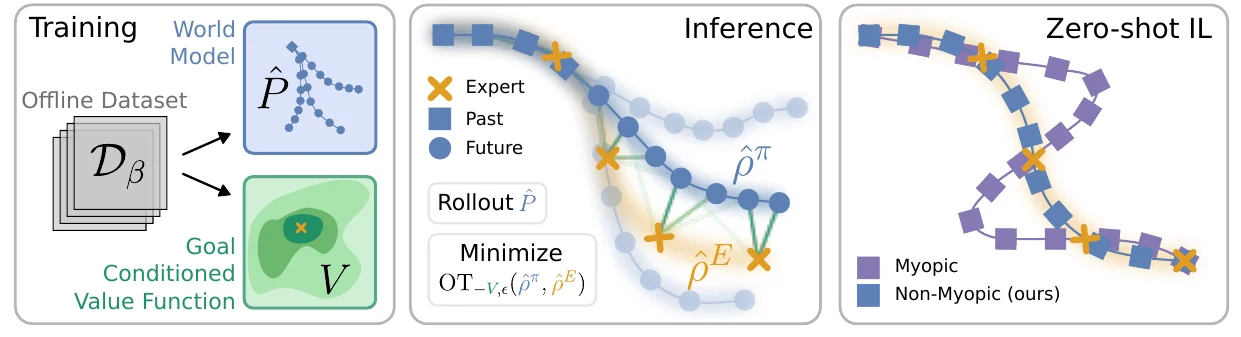
Zero-Shot Offline Imitation Learning via Optimal Transport
International Conference on Machine Learning (ICML)
·
2025
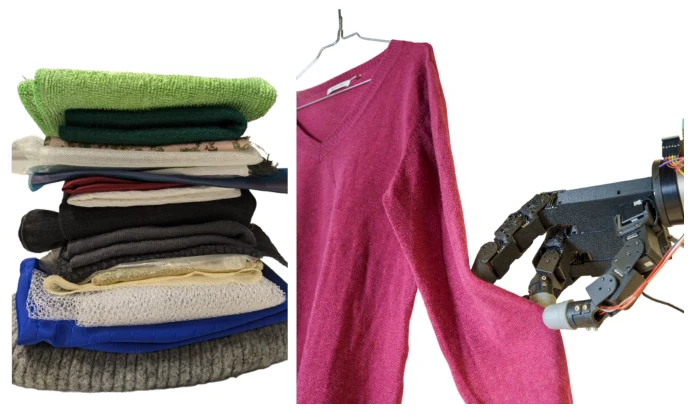
Adding Internal Audio Sensing to Internal Vision Enables Human-Like In-Hand Fabric Recognition with Soft Robotic Fingertips
Proceedings of the IEEE-RAS International Conference on Humanoid Robots (Humanoids)
·
2025
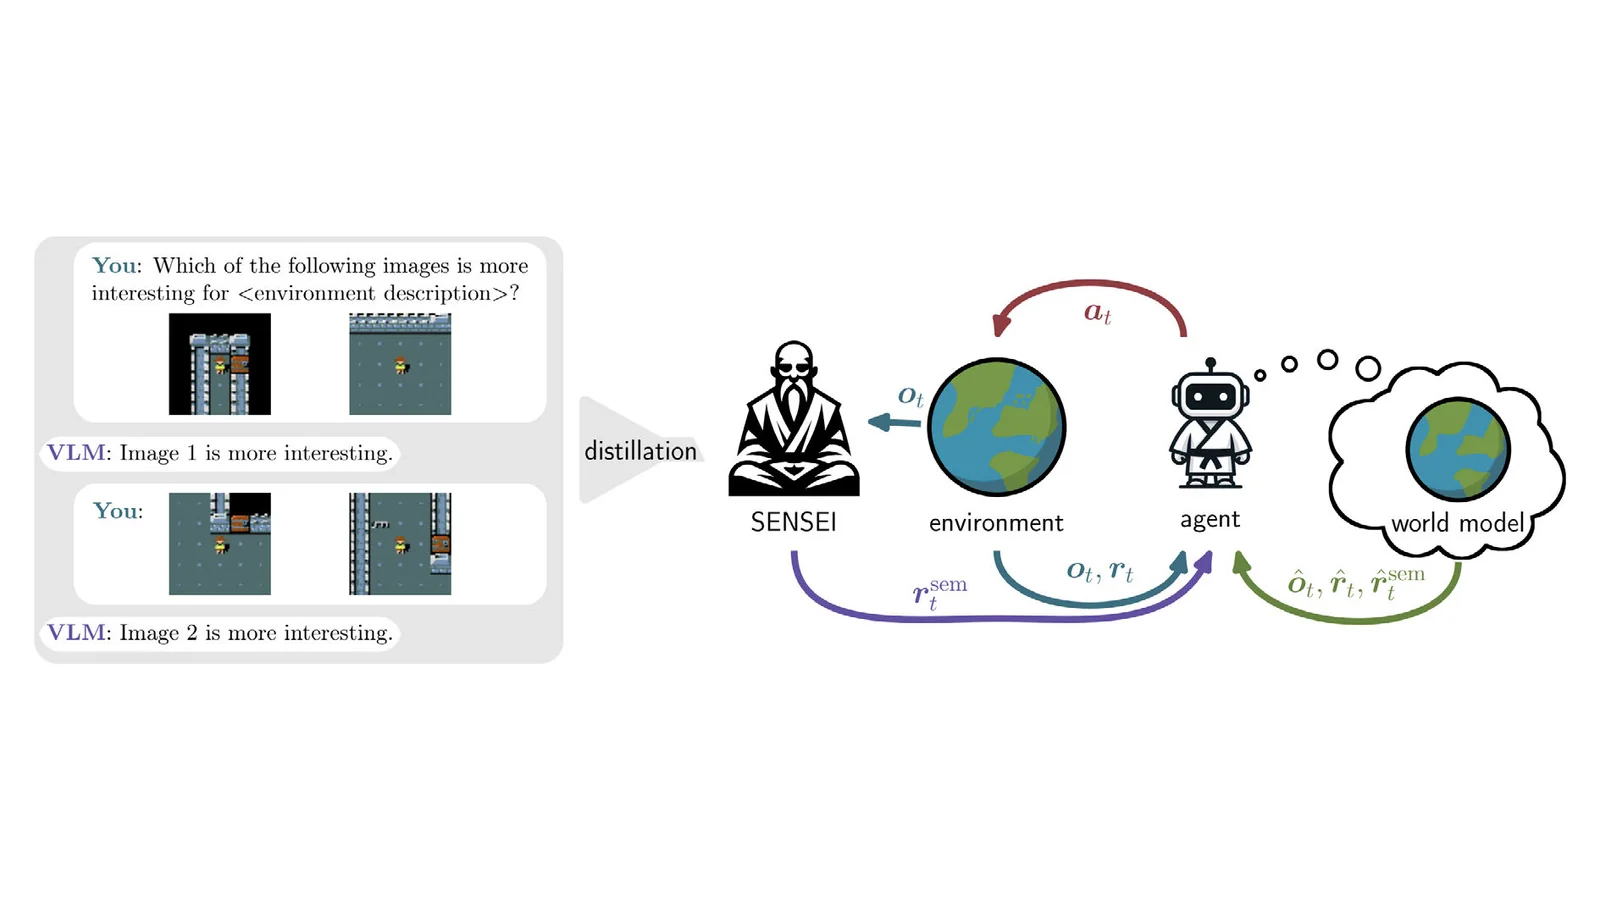
SENSEI: Semantic Exploration Guided by Foundation Models to Learn Versatile World Models
International Conference on Machine Learning (ICML)
·
2025
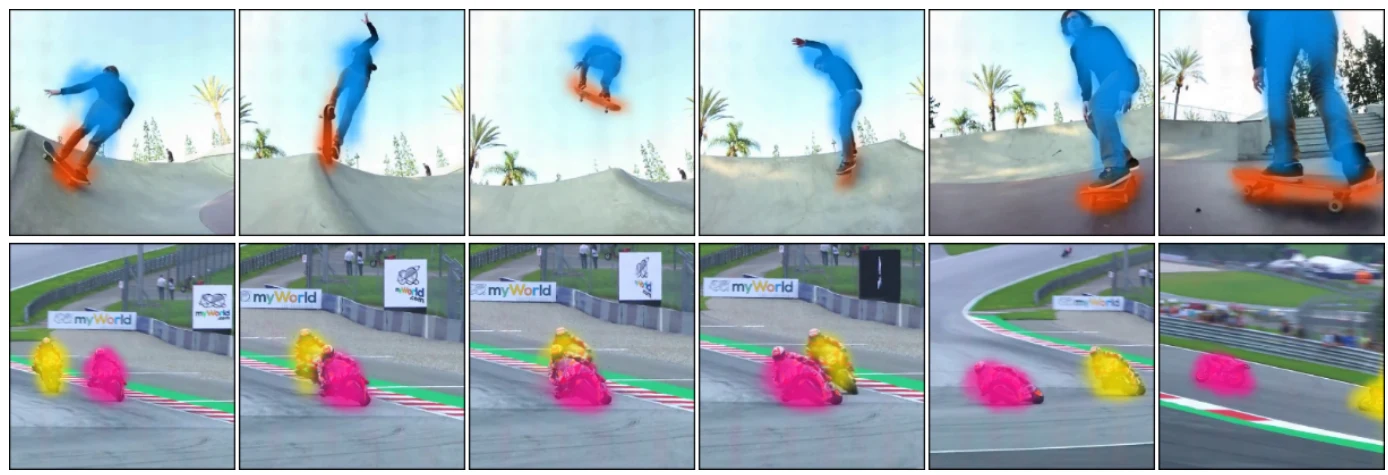
Temporally Consistent Object-Centric Learning by Contrasting Slots
Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR)
·
2025
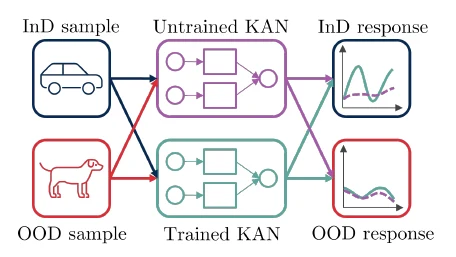
Advancing Out-of-Distribution Detection via Local Neuroplasticity
The Thirteenth International Conference on Learning Representations (ICLR)
·
2025
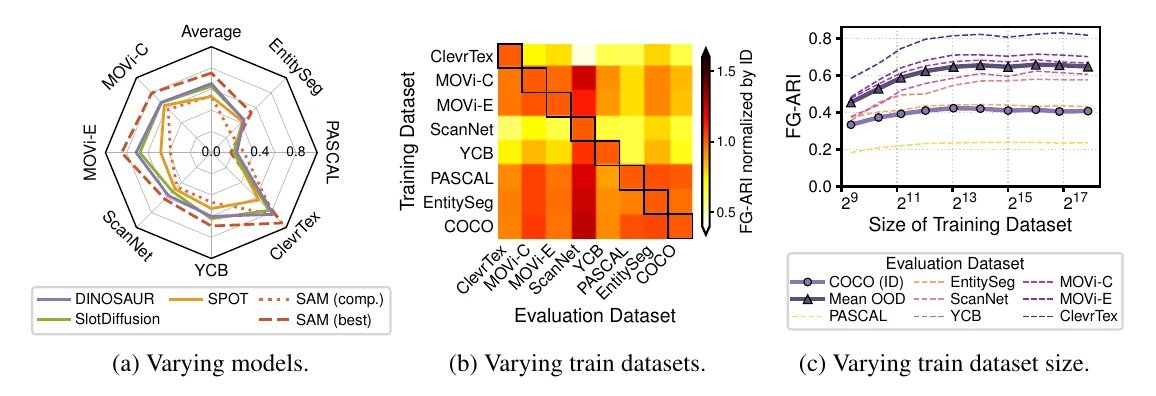
On the Transfer of Object-Centric Representation Learning
The Thirteenth International Conference on Learning Representations (ICLR)
·
2025
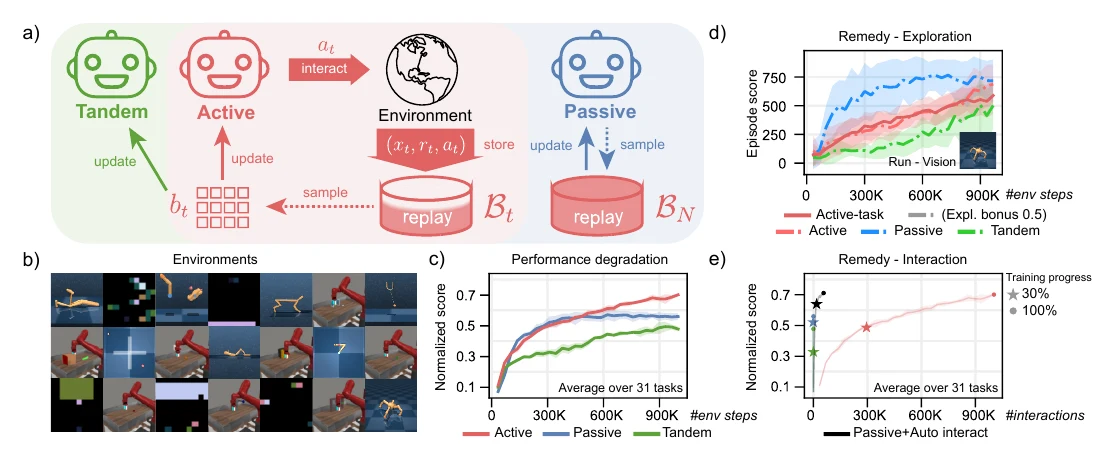
Offline vs. Online Learning in Model-based RL: Lessons for Data Collection Strategies
Reinforcement Learning Journal
·
2025
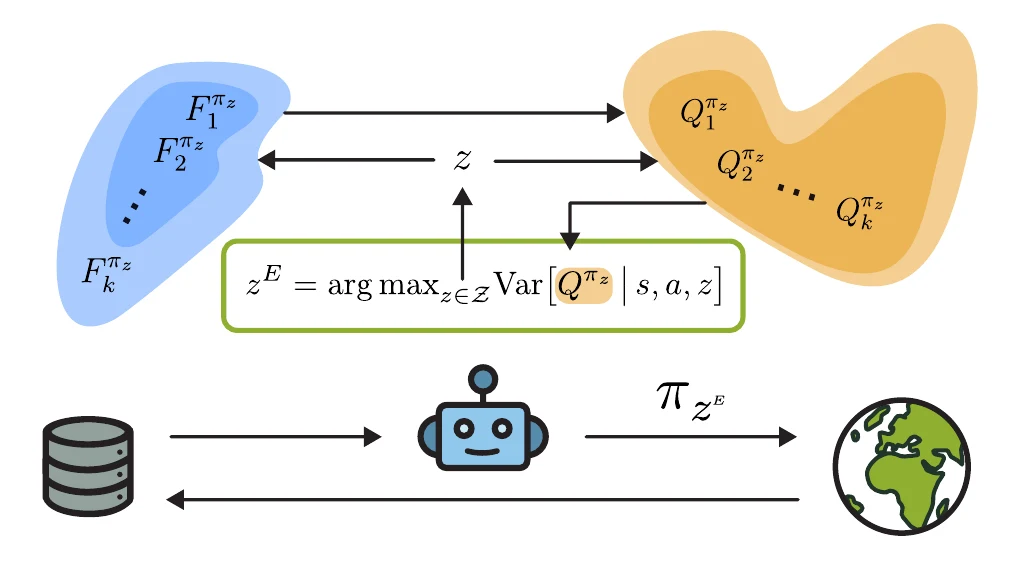
Epistemically-guided forward-backward exploration
Reinforcement Learning Journal
·
2025
Long-Horizon Planning with Predictable Skills
Reinforcement Learning Journal
·
2025
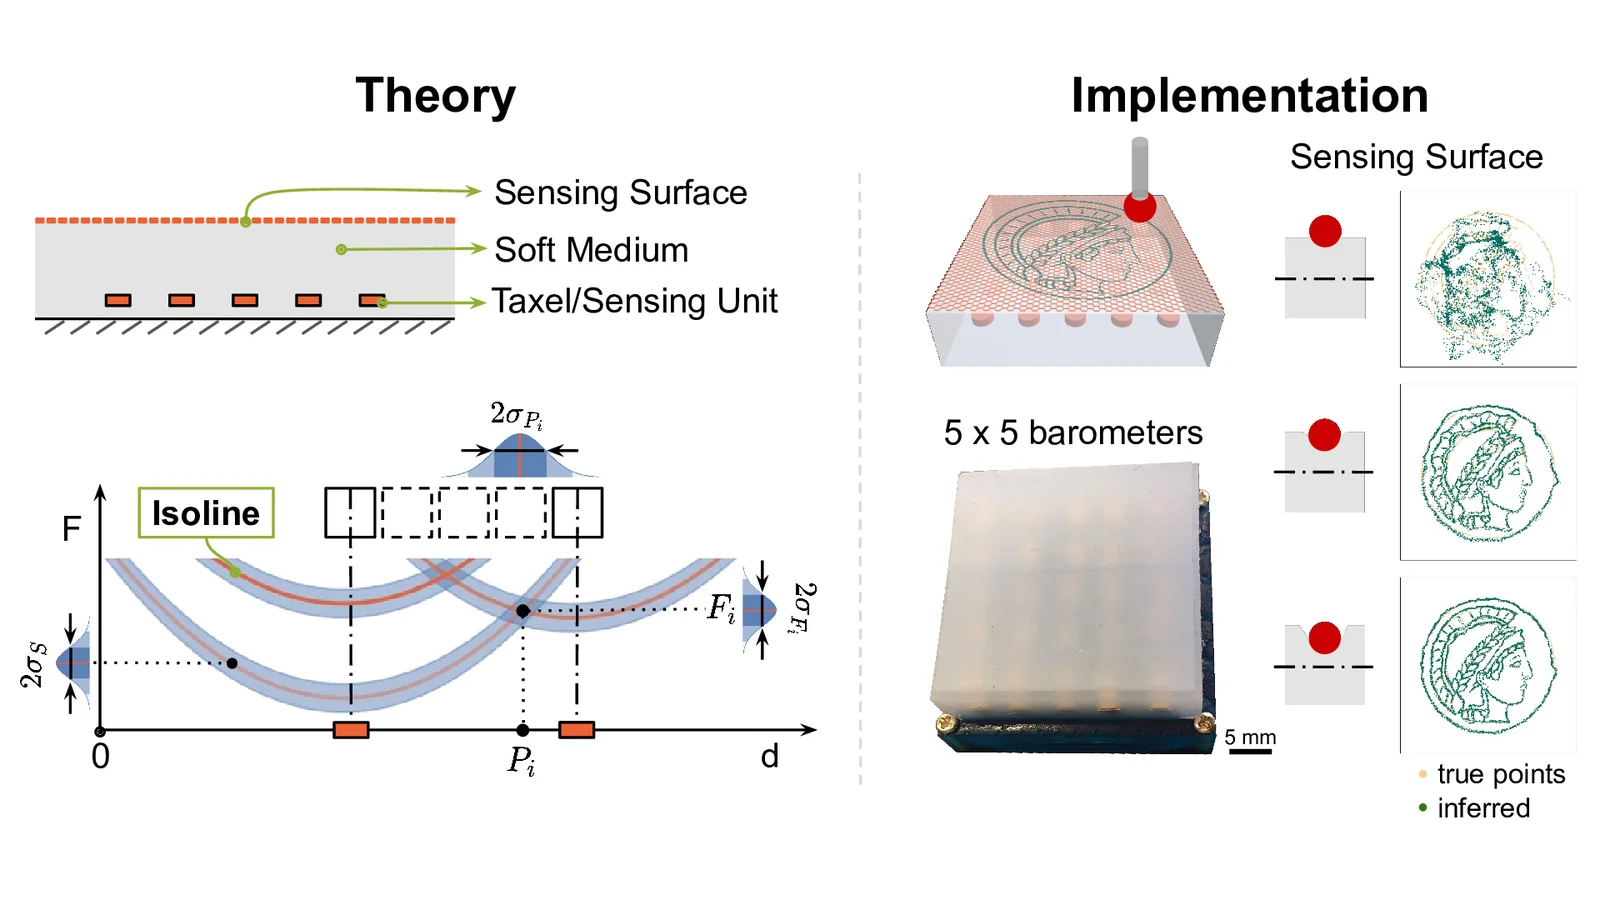
Sensing multi-directional forces at superresolution using taxel value isoline theory
Nature Communications
·
2025
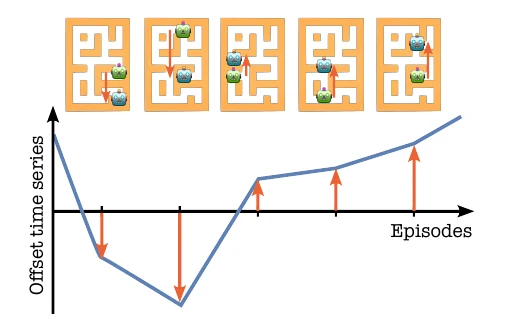
Forecasting in Offline Reinforcement Learning for Non-stationary Environments
The Thirty-ninth Annual Conference on Neural Information Processing Systems
·
2025
2024
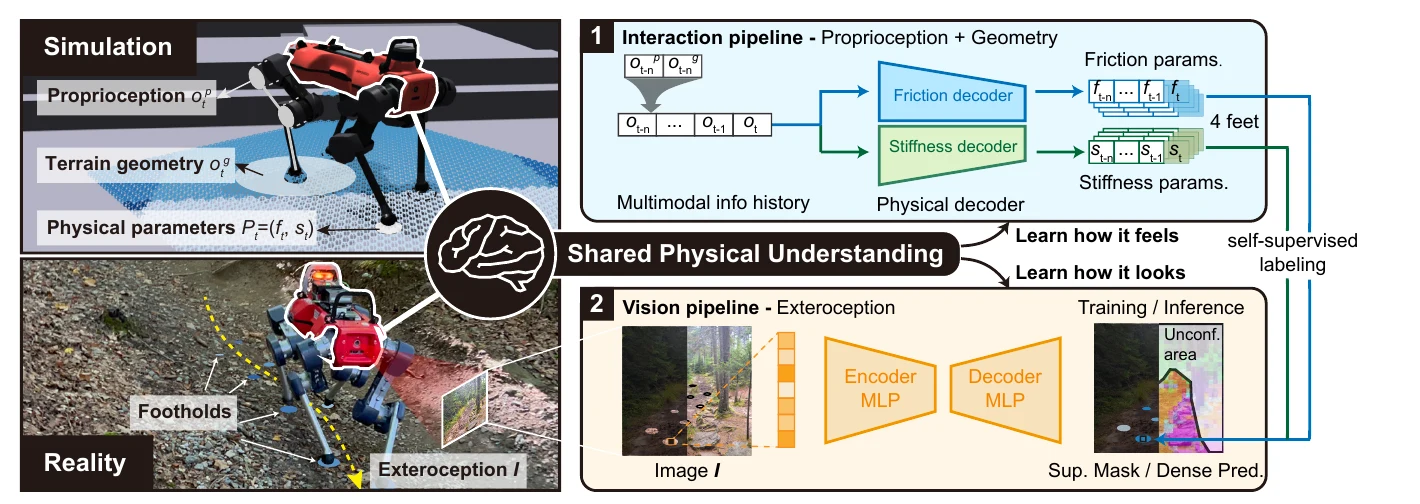
Identifying Terrain Physical Parameters from Vision-Towards Physical-Parameter-Aware Locomotion and Navigation
IEEE Robotics and Automation Letters
·
2024
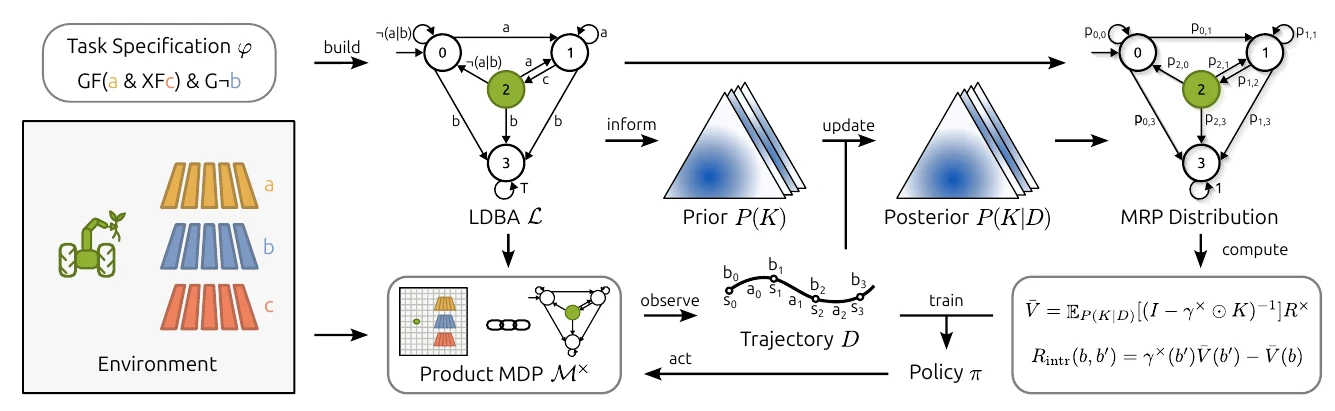
Directed Exploration in Reinforcement Learning from Linear Temporal Logic
arXiv preprint
·
2024
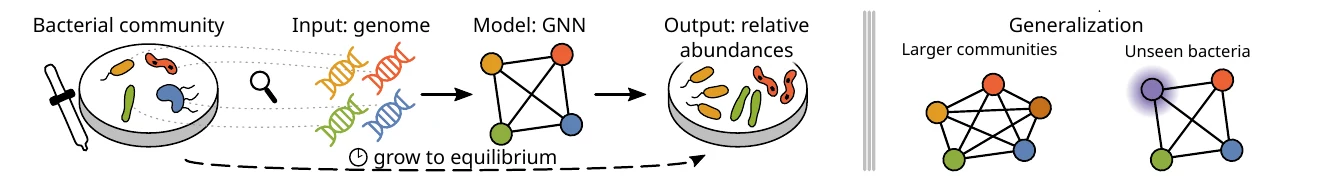
Modelling Microbial Communities with Graph Neural Networks
41st International Conference on Machine Learning (ICML)
·
2024
LPGD: A General Framework for Backpropagation through Embedded Optimization Layers
41st International Conference on Machine Learning (ICML)
·
2024
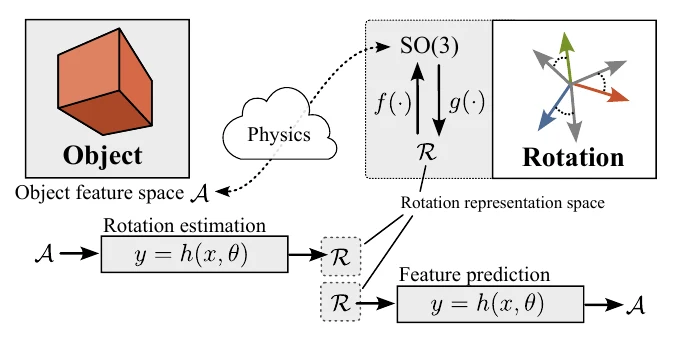
Learning with 3D rotations, a hitchhiker's guide to SO(3)
41st International Conference on Machine Learning (ICML)
·
2024
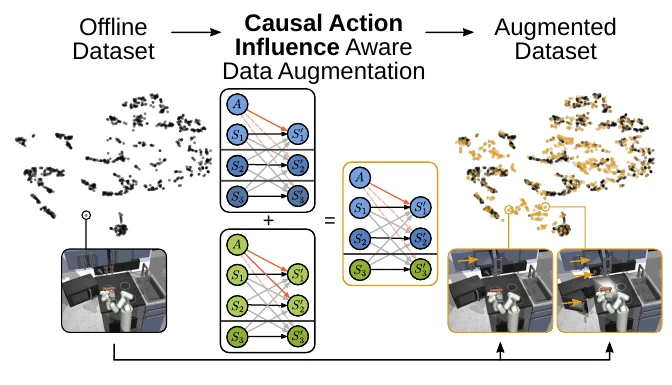
Causal Action Influence Aware Counterfactual Data Augmentation
41st International Conference on Machine Learning (ICML)
·
2024
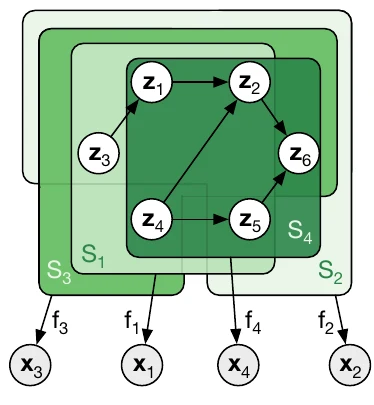
Multi-View Causal Representation Learning with Partial Observability
The Twelfth International Conference on Learning Representations (ICLR)
·
2024
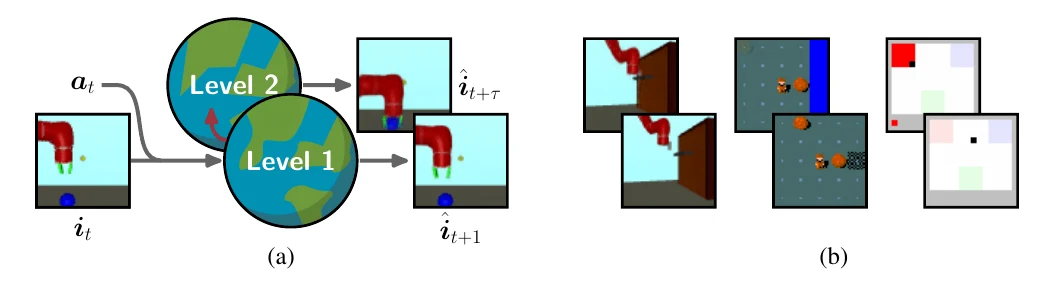
Learning Hierarchical World Models with Adaptive Temporal Abstractions from Discrete Latent Dynamics
The Twelfth International Conference on Learning Representations
·
2024
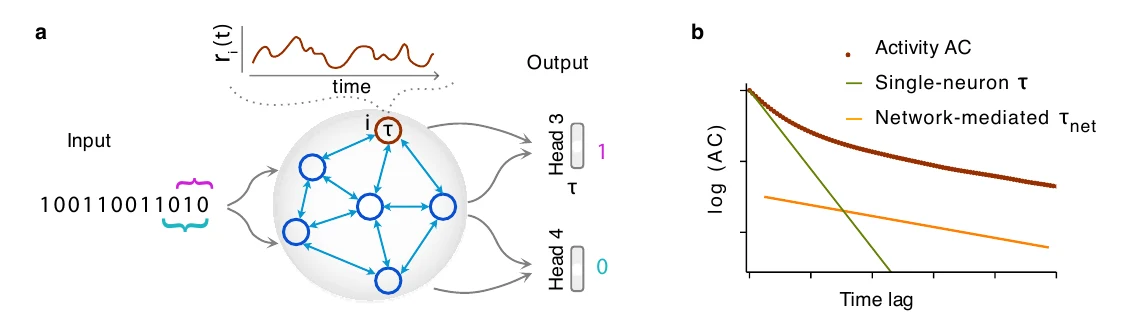
Emergent mechanisms for long timescales depend on training curriculum and affect performance in memory tasks
The Twelfth International Conference on Learning Representations
·
2024
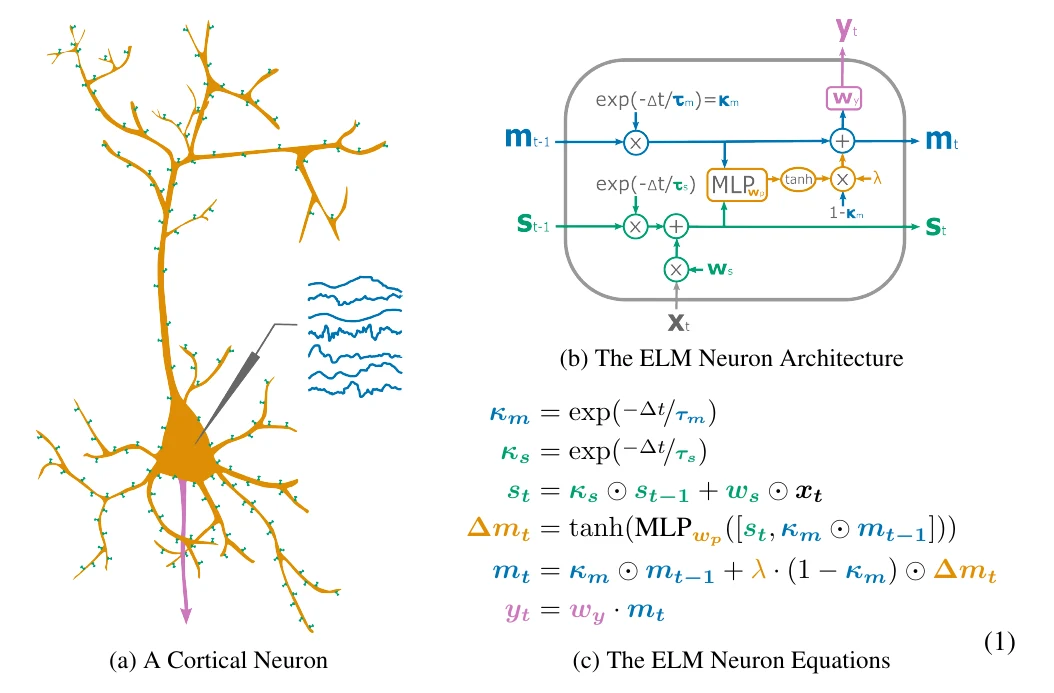
The Expressive Leaky Memory Neuron: an Efficient and Expressive Phenomenological Neuron Model Can Solve Long-Horizon Tasks
The Twelfth International Conference on Learning Representations (ICLR)
·
2024
Offline Diversity Maximization Under Imitation Constraints
arXiv preprint
·
2024
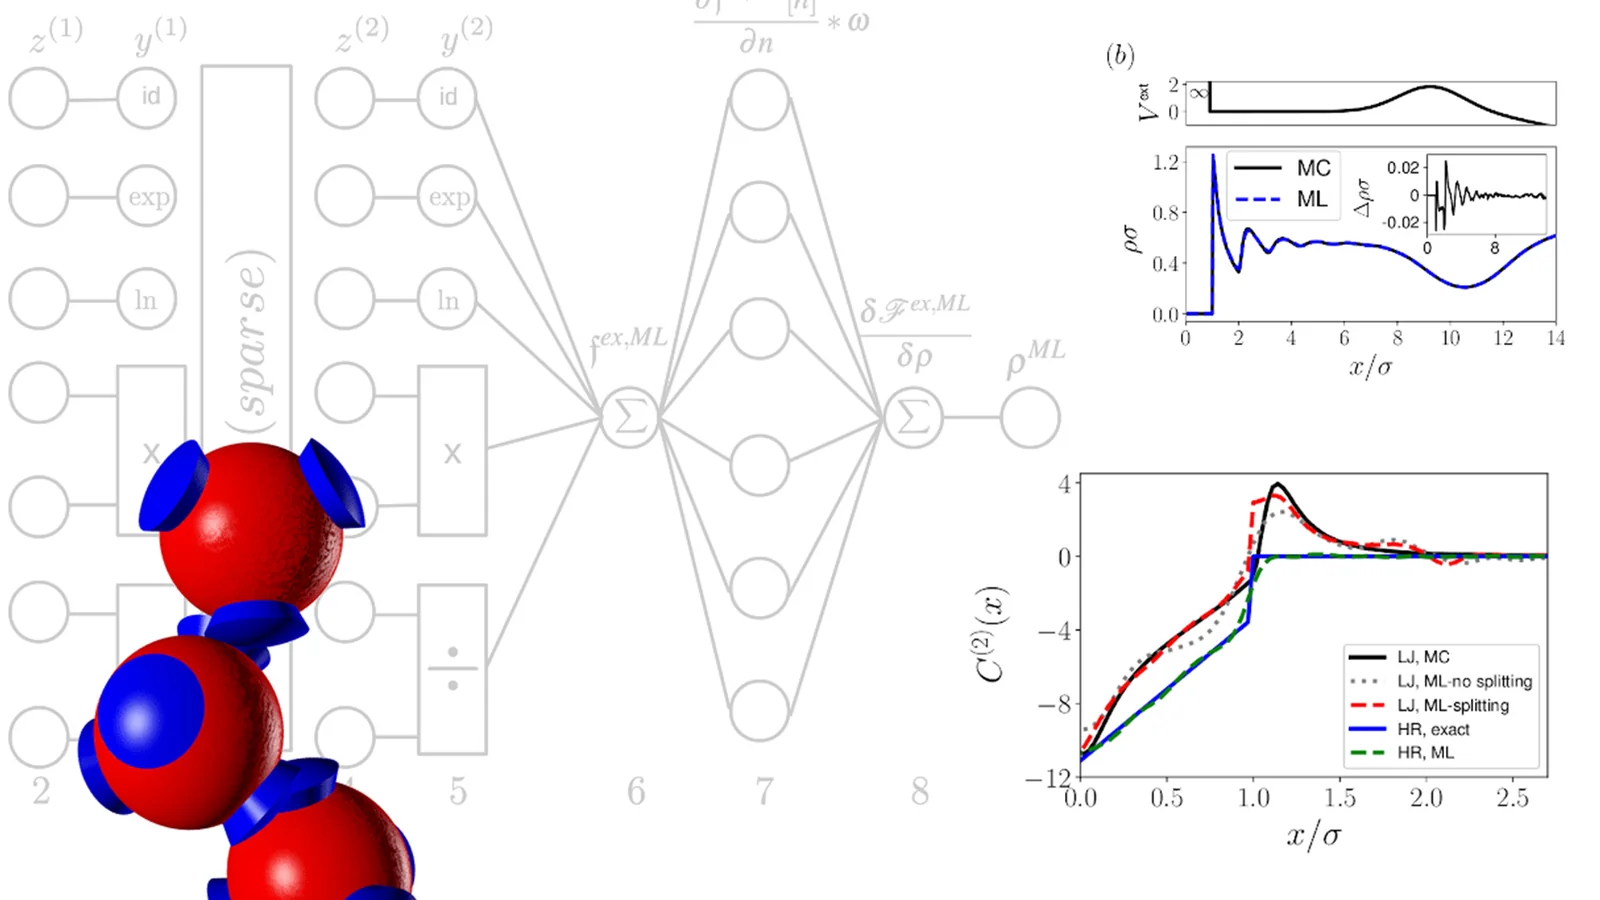
Machine learning of a density functional for anisotropic patchy particles
Journal of Chemical Theory and Computation
·
2024
2023
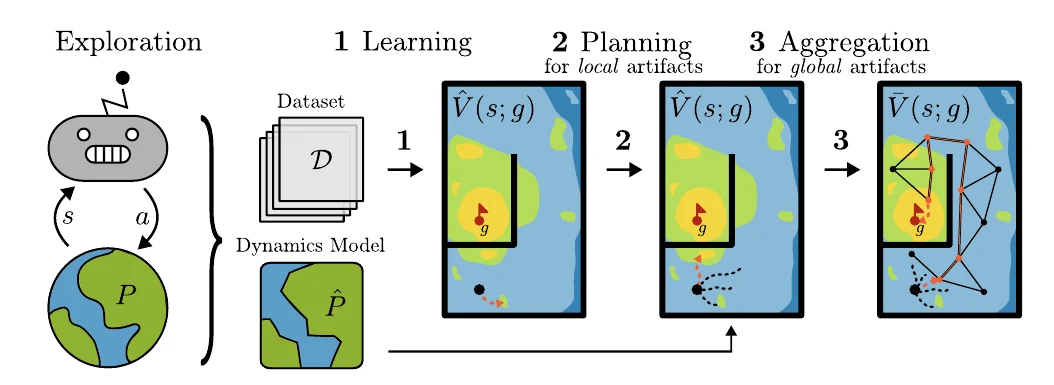
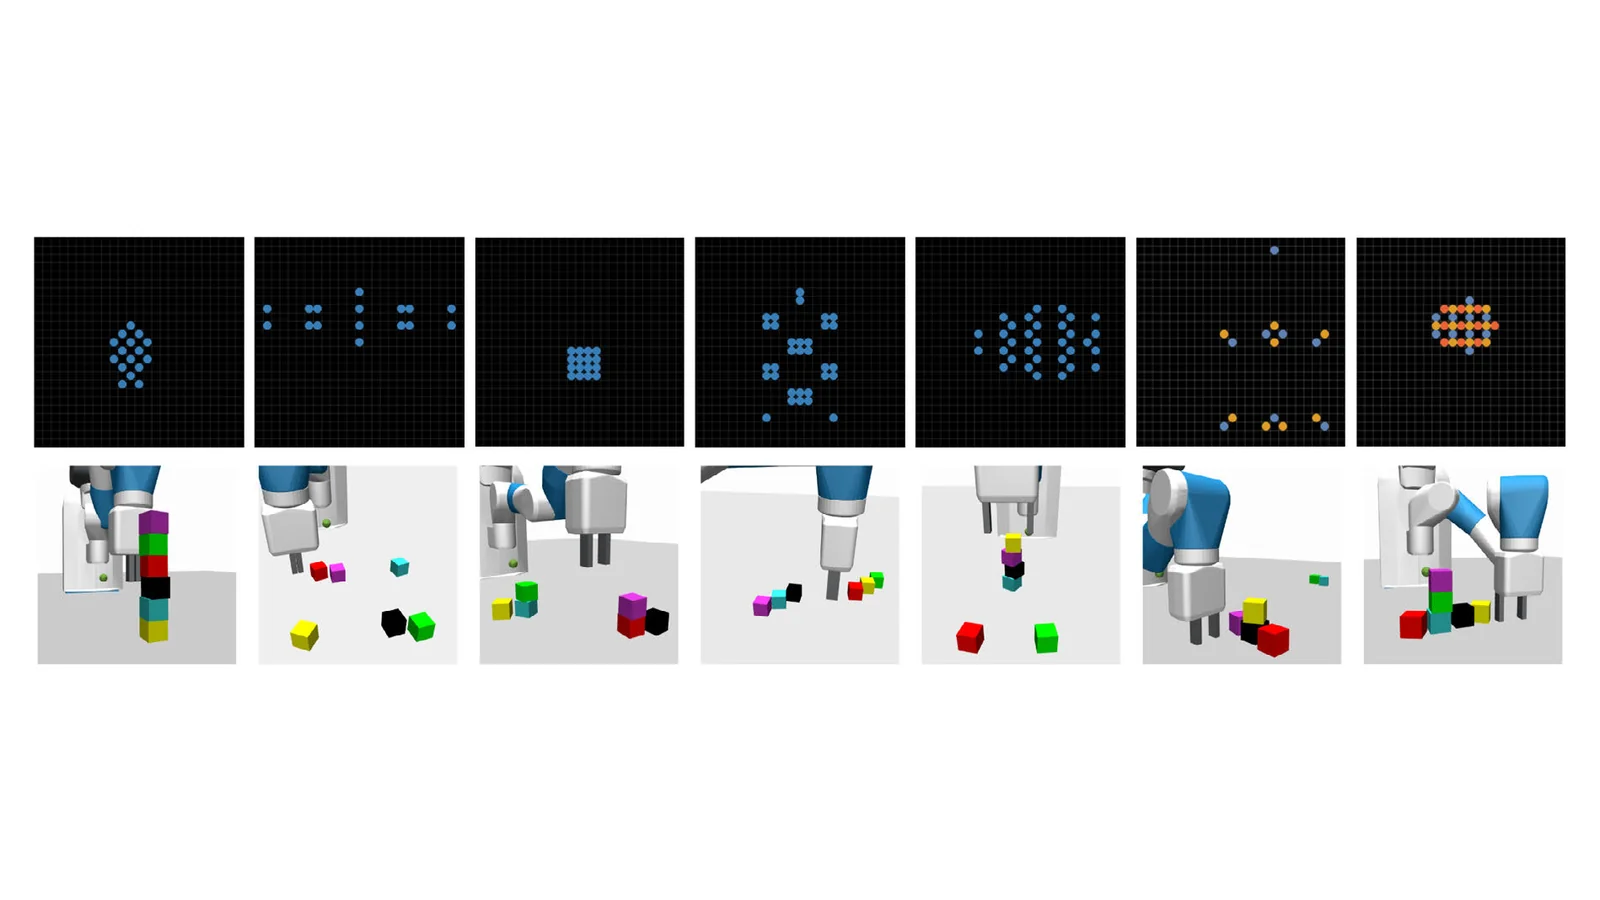
Regularity as Intrinsic Reward for Free Play
Advances in Neural Information Processing Systems 37
·
2023
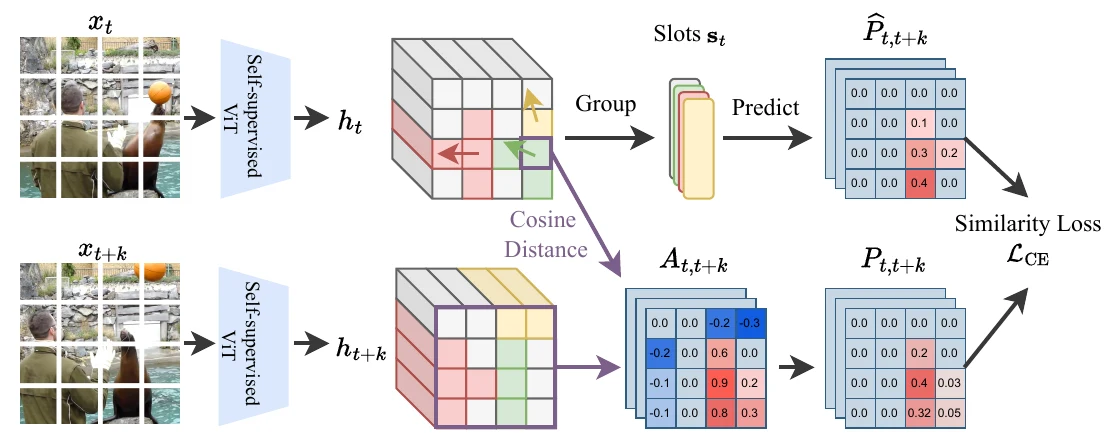
Object-Centric Learning for Real-World Videos by Predicting Temporal Feature Similarities
Thirty-seventh Conference on Neural Information Processing Systems (NeurIPS 2023)
·
2023
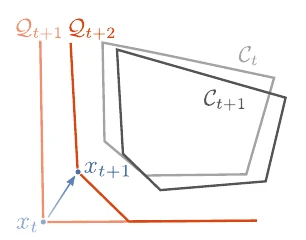
Online Learning under Adversarial Nonlinear Constraints
Advances in Neural Information Processing Systems 36
·
2023
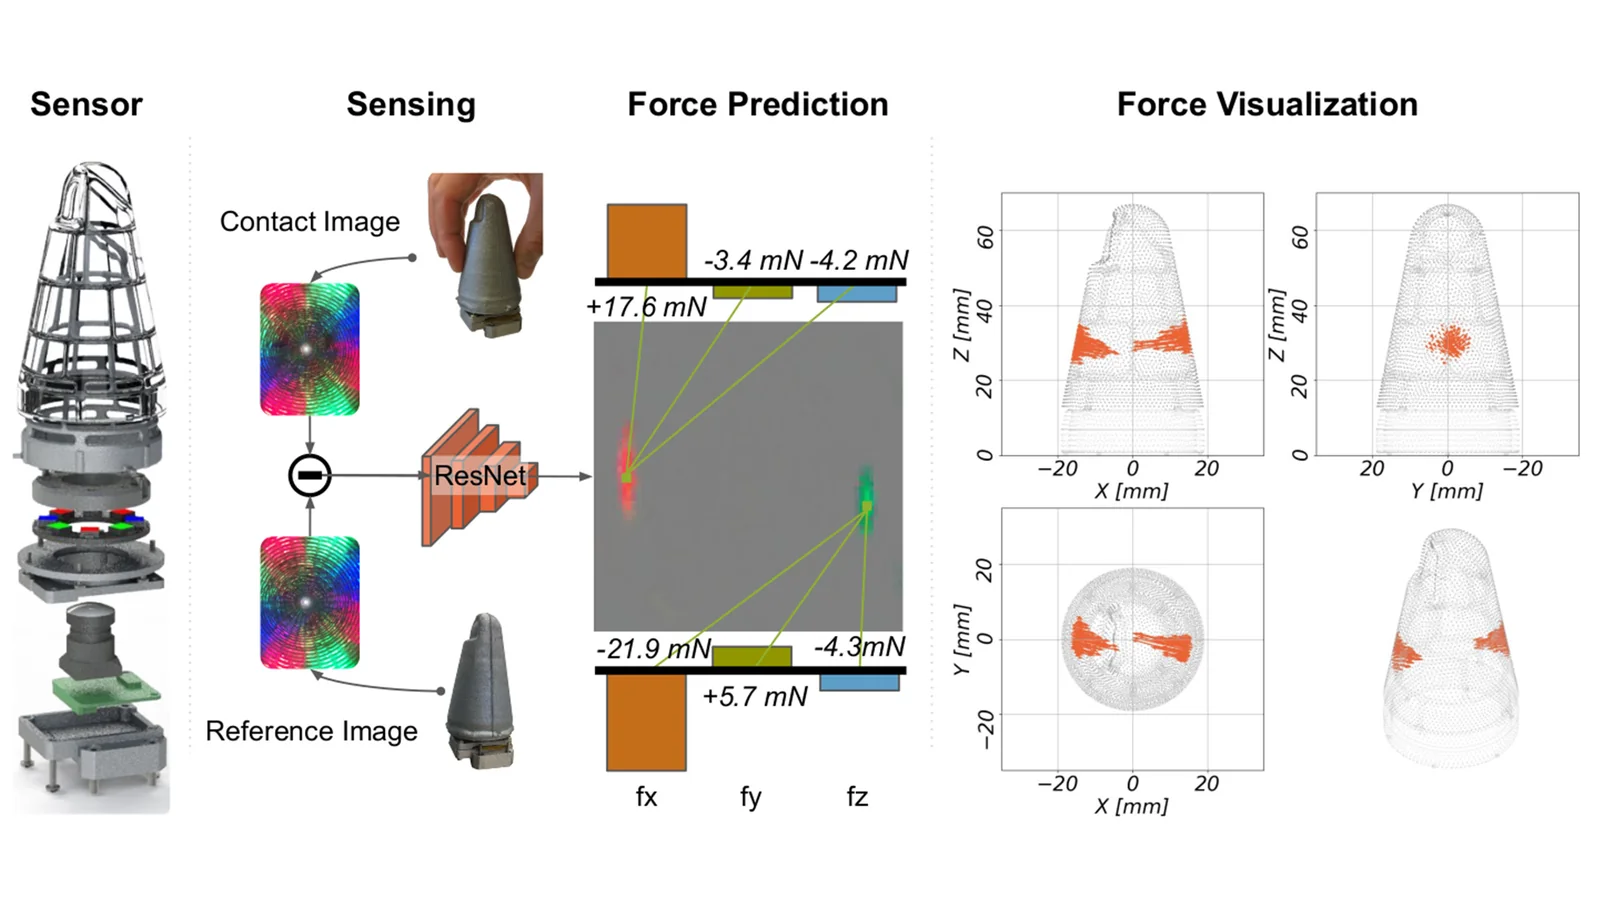
Minsight: A Fingertip-Sized Vision-Based Tactile Sensor for Robotic Manipulation
Advanced Intelligent Systems
·
2023
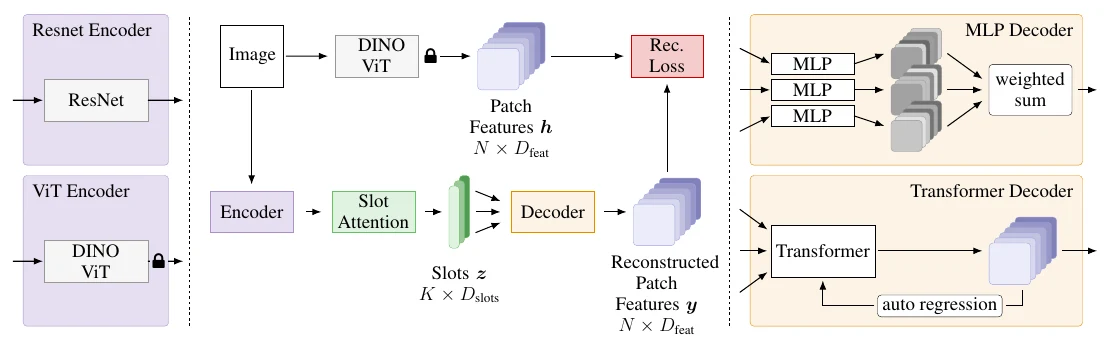
Bridging the Gap to Real-World Object-Centric Learning
Proceedings of the Eleventh International Conference on Learning Representations
·
2023
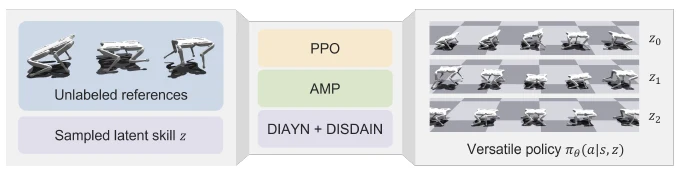
Versatile Skill Control via Self-supervised Adversarial Imitation of Unlabeled Mixed Motions
Proceedings of the IEEE International Conference on Robotics and Automation (ICRA)
·
2023
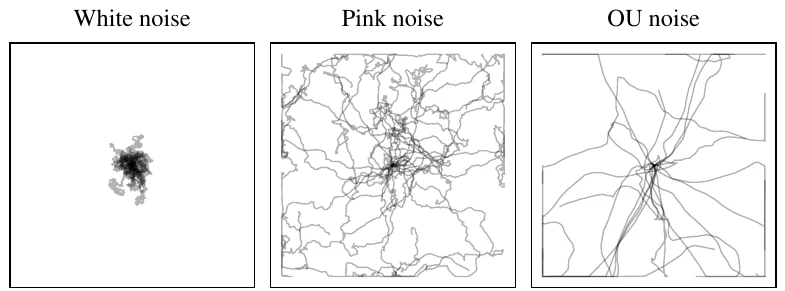
Pink Noise Is All You Need: Colored Noise Exploration in Deep Reinforcement Learning
Proceedings of the Eleventh International Conference on Learning Representations (ICLR)
·
2023
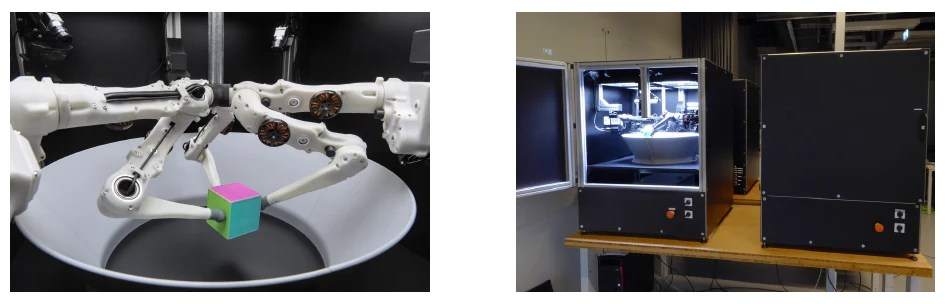
Benchmarking Offline Reinforcement Learning on Real-Robot Hardware
Proceedings of the Eleventh International Conference on Learning Representations
·
2023
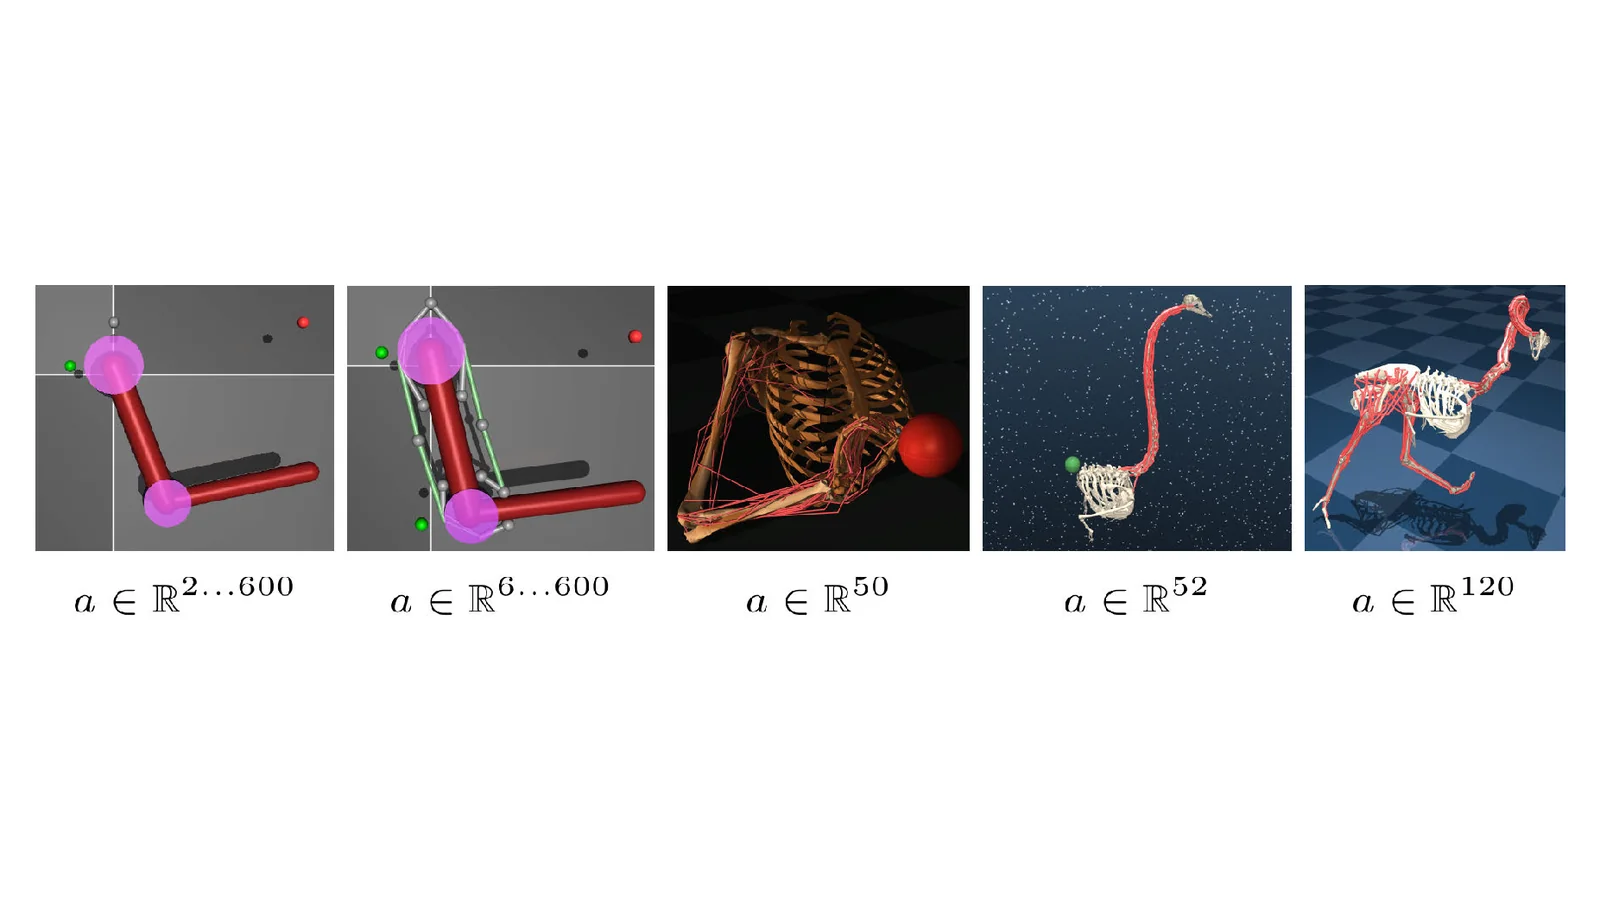
DEP-RL: Embodied Exploration for Reinforcement Learning in Overactuated and Musculoskeletal Systems
Proceedings of the Eleventh International Conference on Learning Representations (ICLR)
·
2023
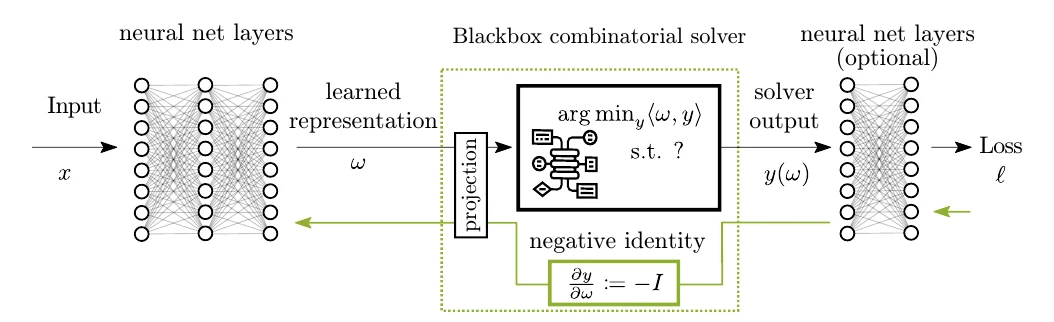
Backpropagation through Combinatorial Algorithms: Identity with Projection Works
Proceedings of the Eleventh International Conference on Learning Representations
·
2023
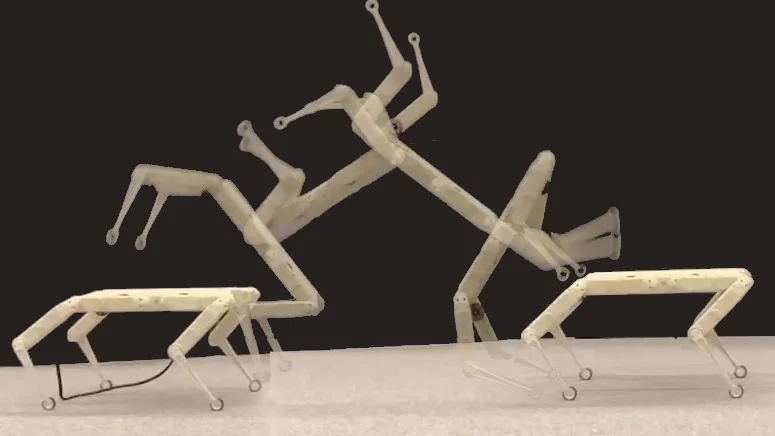
Learning Agile Skills via Adversarial Imitation of Rough Partial Demonstrations
Proceedings of the 6th Conference on Robot Learning (CoRL)
·
2023
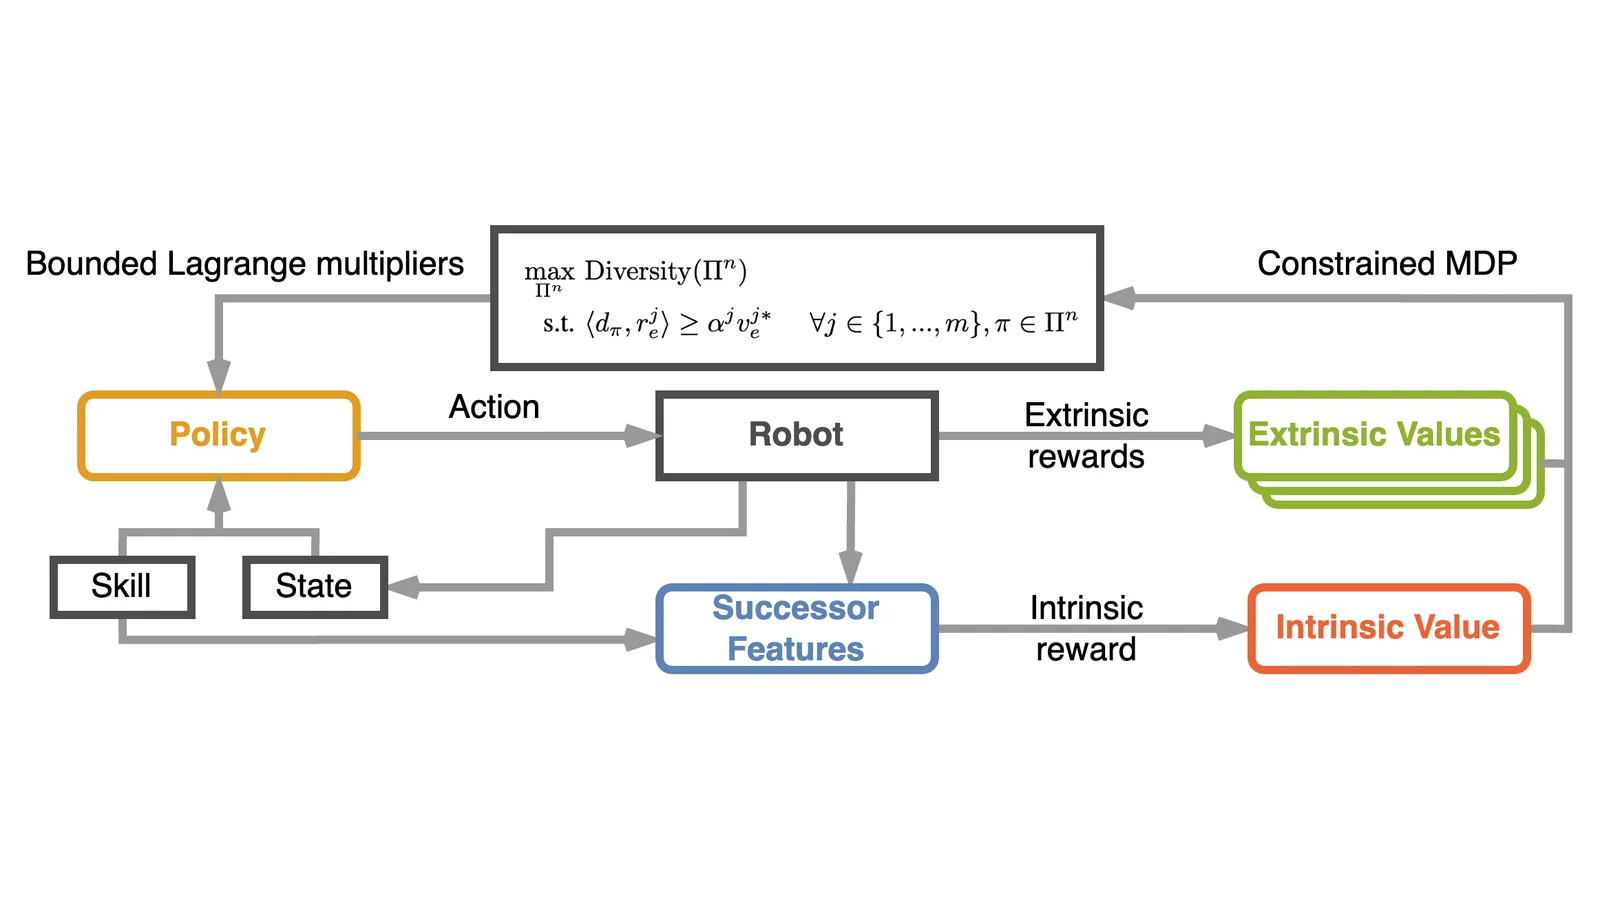
Learning Diverse Skills for Local Navigation under Multi-constraint Optimality
arXiv preprint
·
2023
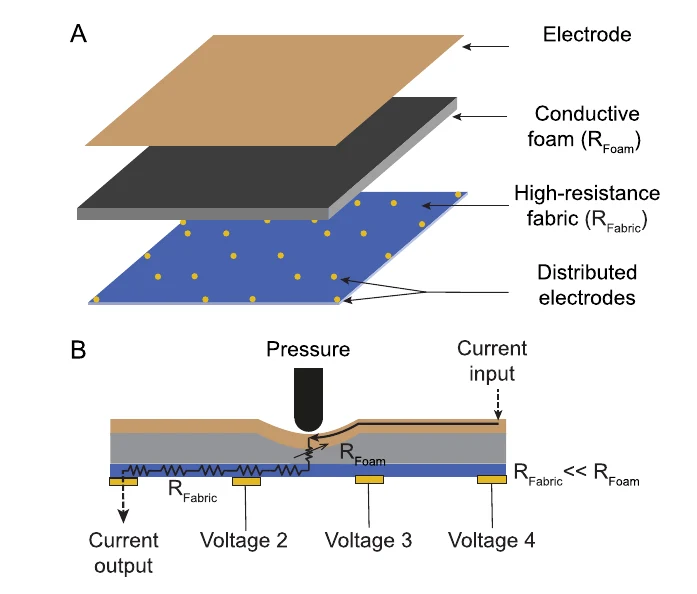
Predicting the Force Map of an ERT-Based Tactile Sensor Using Simulation and Deep Networks
IEEE Transactions on Automation Science and Engineering
·
2023
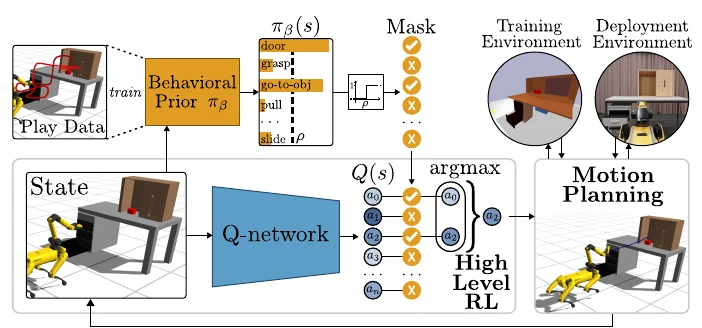
Efficient Learning of High Level Plans from Play
International Conference on Robotics and Automation
·
2023
2022
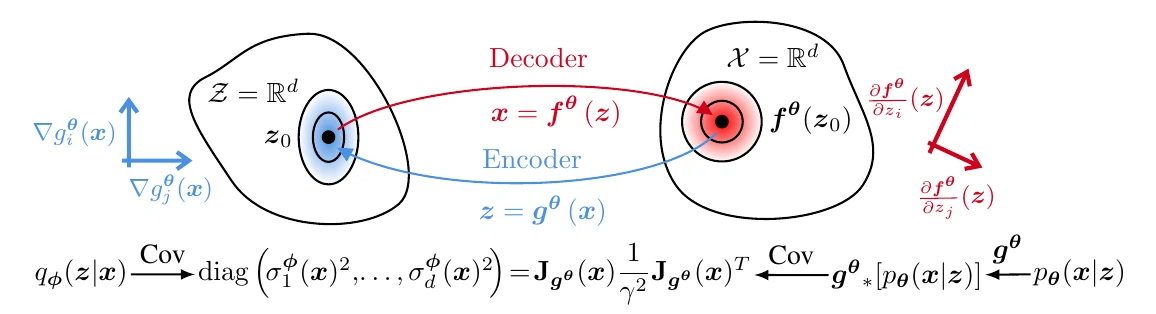
Embrace the Gap: VAEs Perform Independent Mechanism Analysis
Advances in Neural Information Processing Systems 35 (NeurIPS 2022)
·
2022
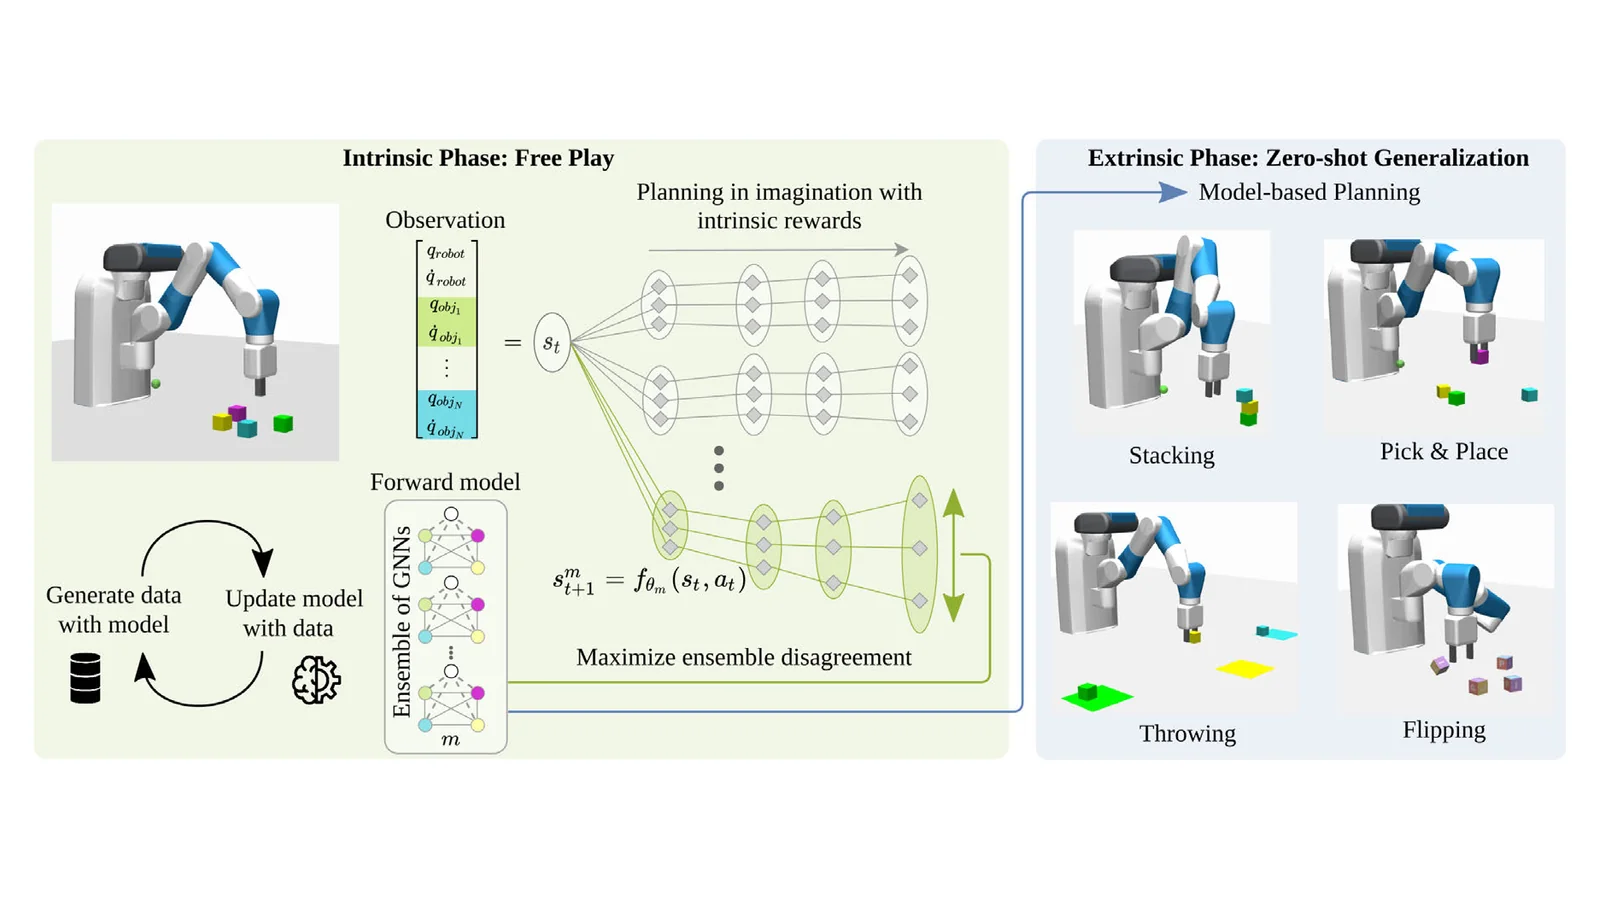
Curious Exploration via Structured World Models Yields Zero-Shot Object Manipulation
Advances in Neural Information Processing Systems 35 (NeurIPS 2022)
·
2022
A Sequential Group VAE for Robot Learning of Haptic Representations
Workshop paper (8 pages) presented at the CoRL Workshop on Aligning Robot Representations with Humans
·
2022
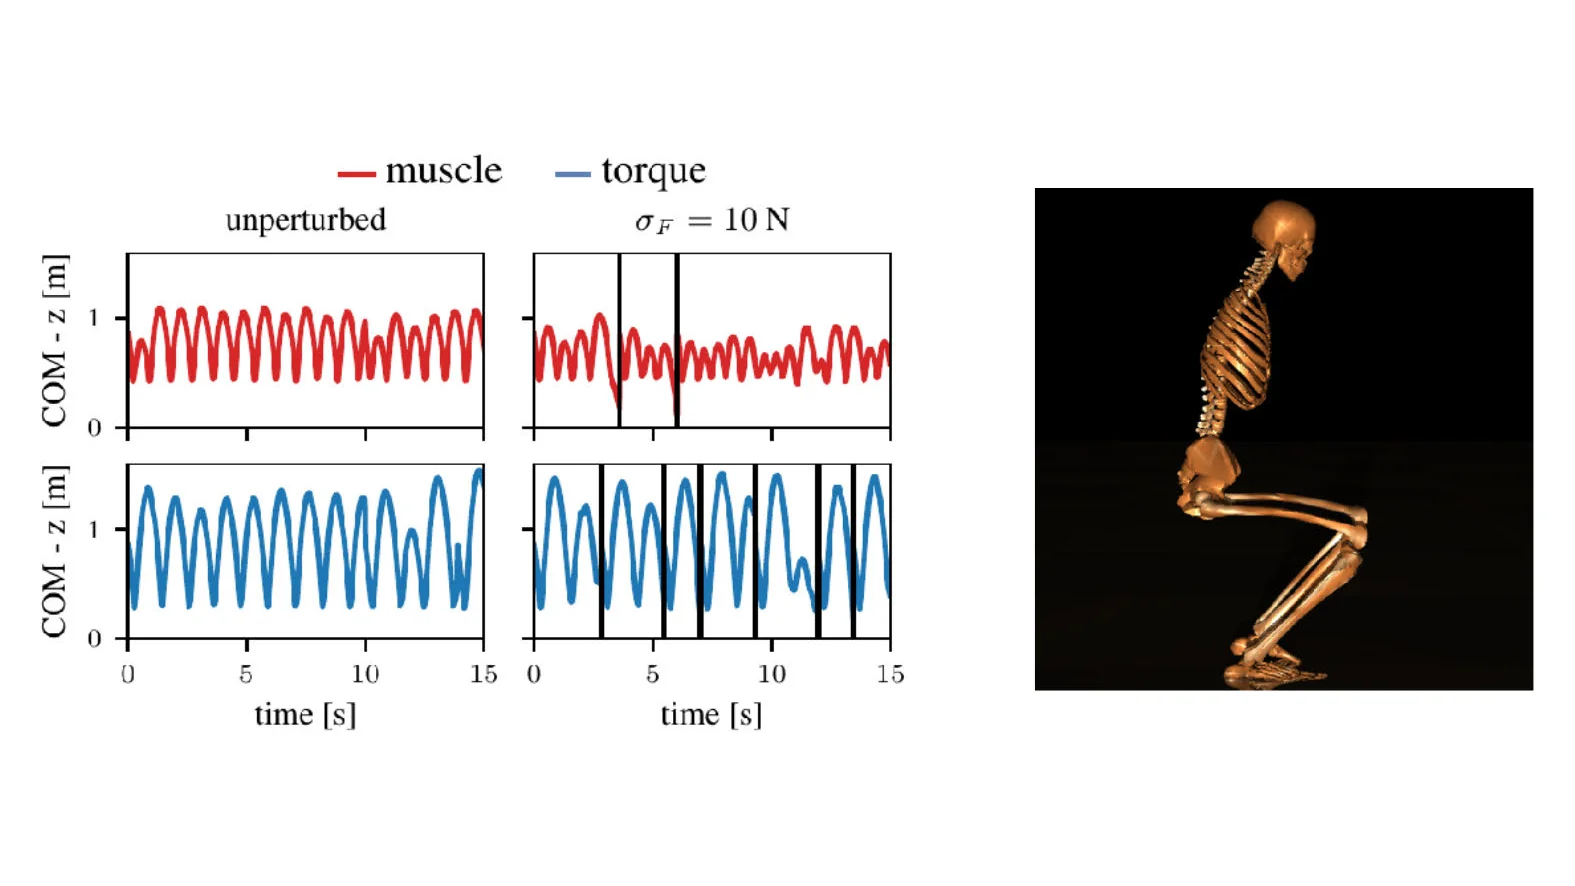
Learning with Muscles: Benefits for Data-Efficiency and Robustness in Anthropomorphic Tasks
Proceedings of the 6th Conference on Robot Learning (CoRL)
·
2022
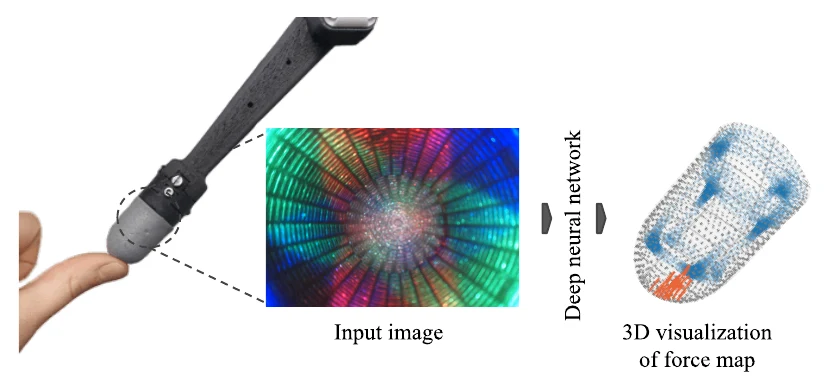
A Soft Vision-Based Tactile Sensor for Robotic Fingertip Manipulation
Workshop paper (1 page) presented at the IROS Workshop on Large-Scale Robotic Skin: Perception, Interaction and Control
·
2022
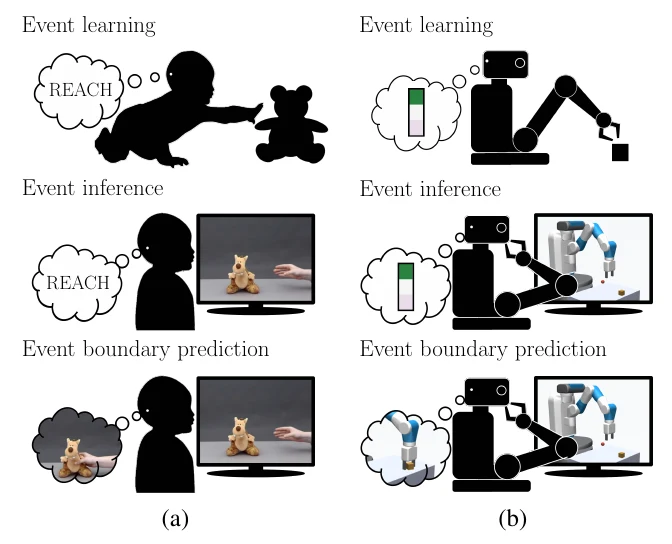
Developing hierarchical anticipations via neural network-based event segmentation
Proceedings of the IEEE International Conference on Development and Learning (ICDL 2022)
·
2022
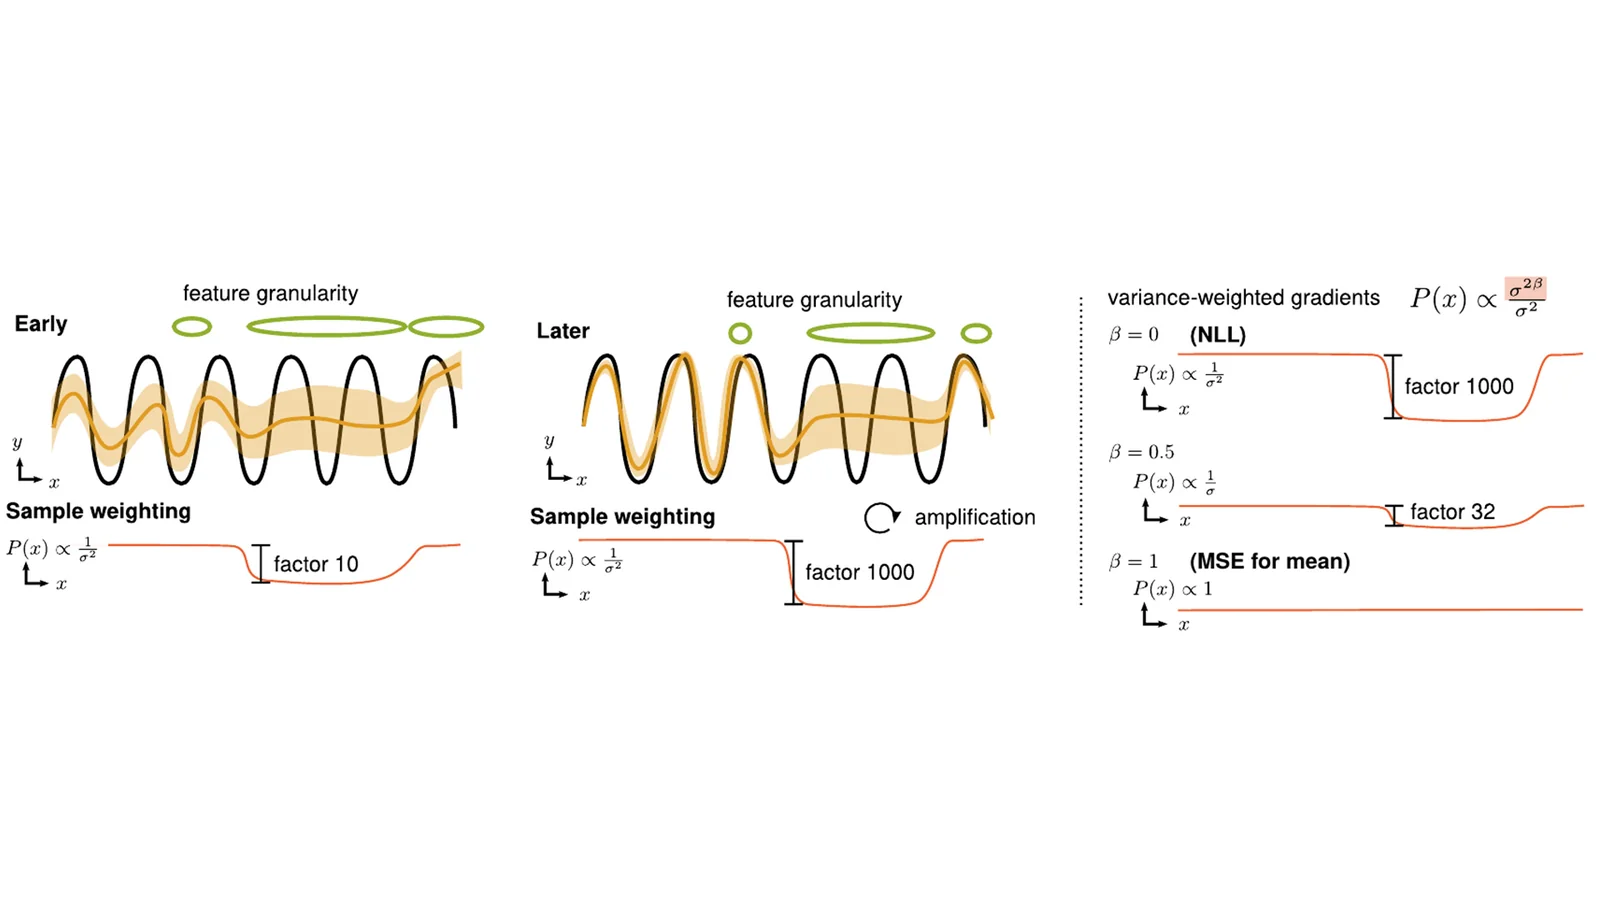
On the Pitfalls of Heteroscedastic Uncertainty Estimation with Probabilistic Neural Networks
International Conference on Learning Representations
·
2022
A Soft Thumb-Sized Vision-Based Sensor with Accurate All-Round Force Perception
Nature Machine Intelligence
·
2022
Guiding the Design of Super-resolution Tactile Skins with Taxel Value Isolines Theory
Science Robotics
·
2022
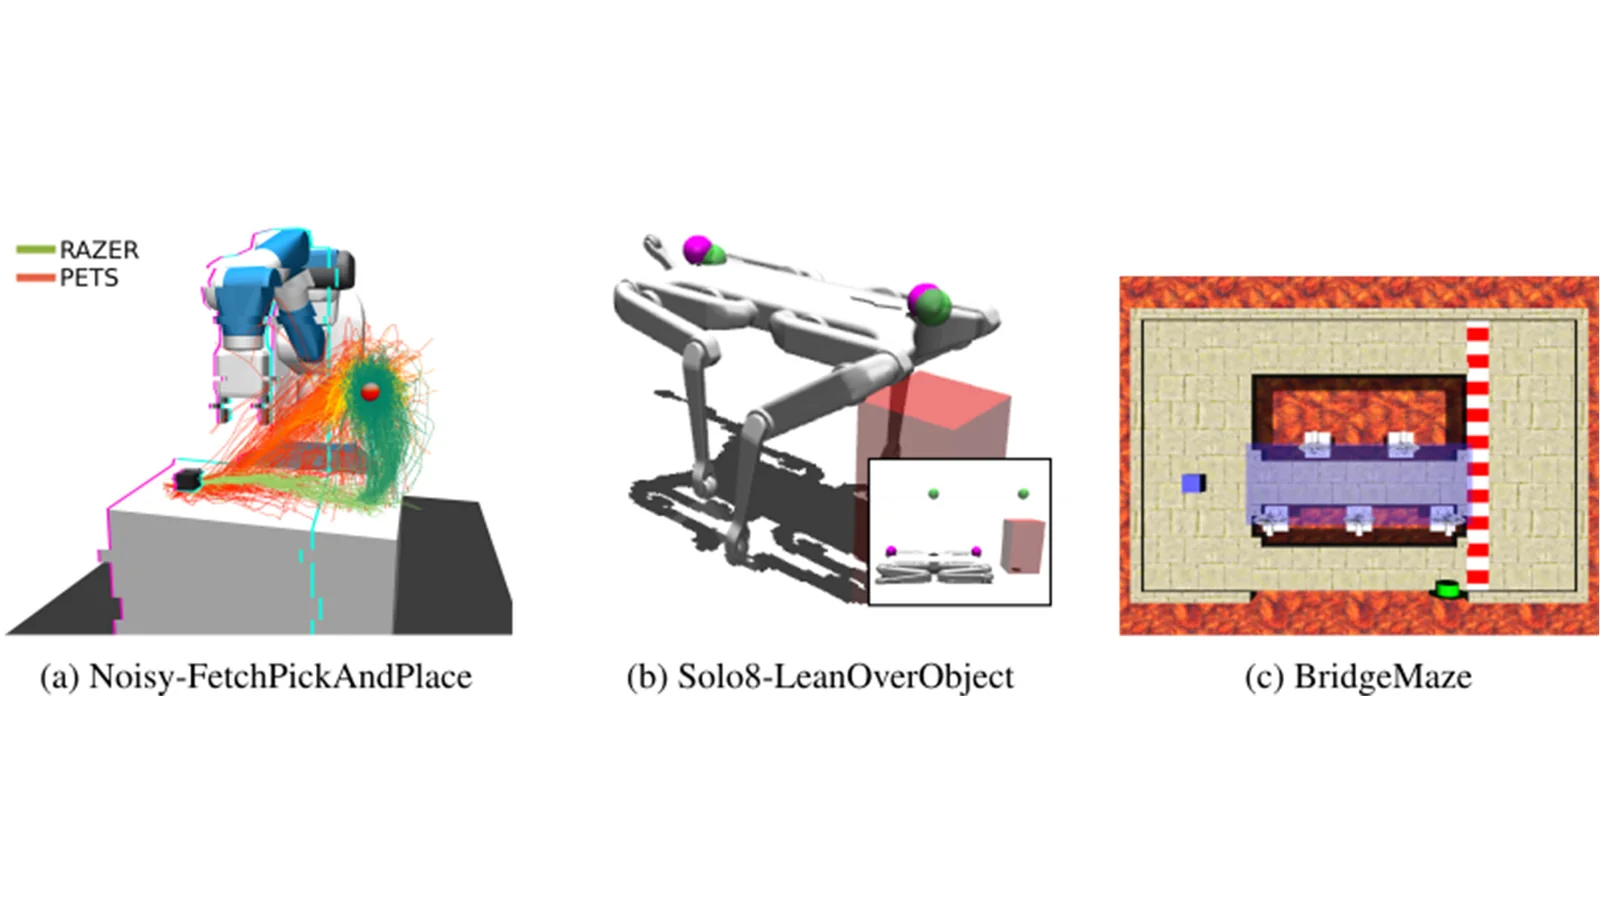
Risk-Averse Zero-Order Trajectory Optimization
Conference on Robot Learning
·
2022
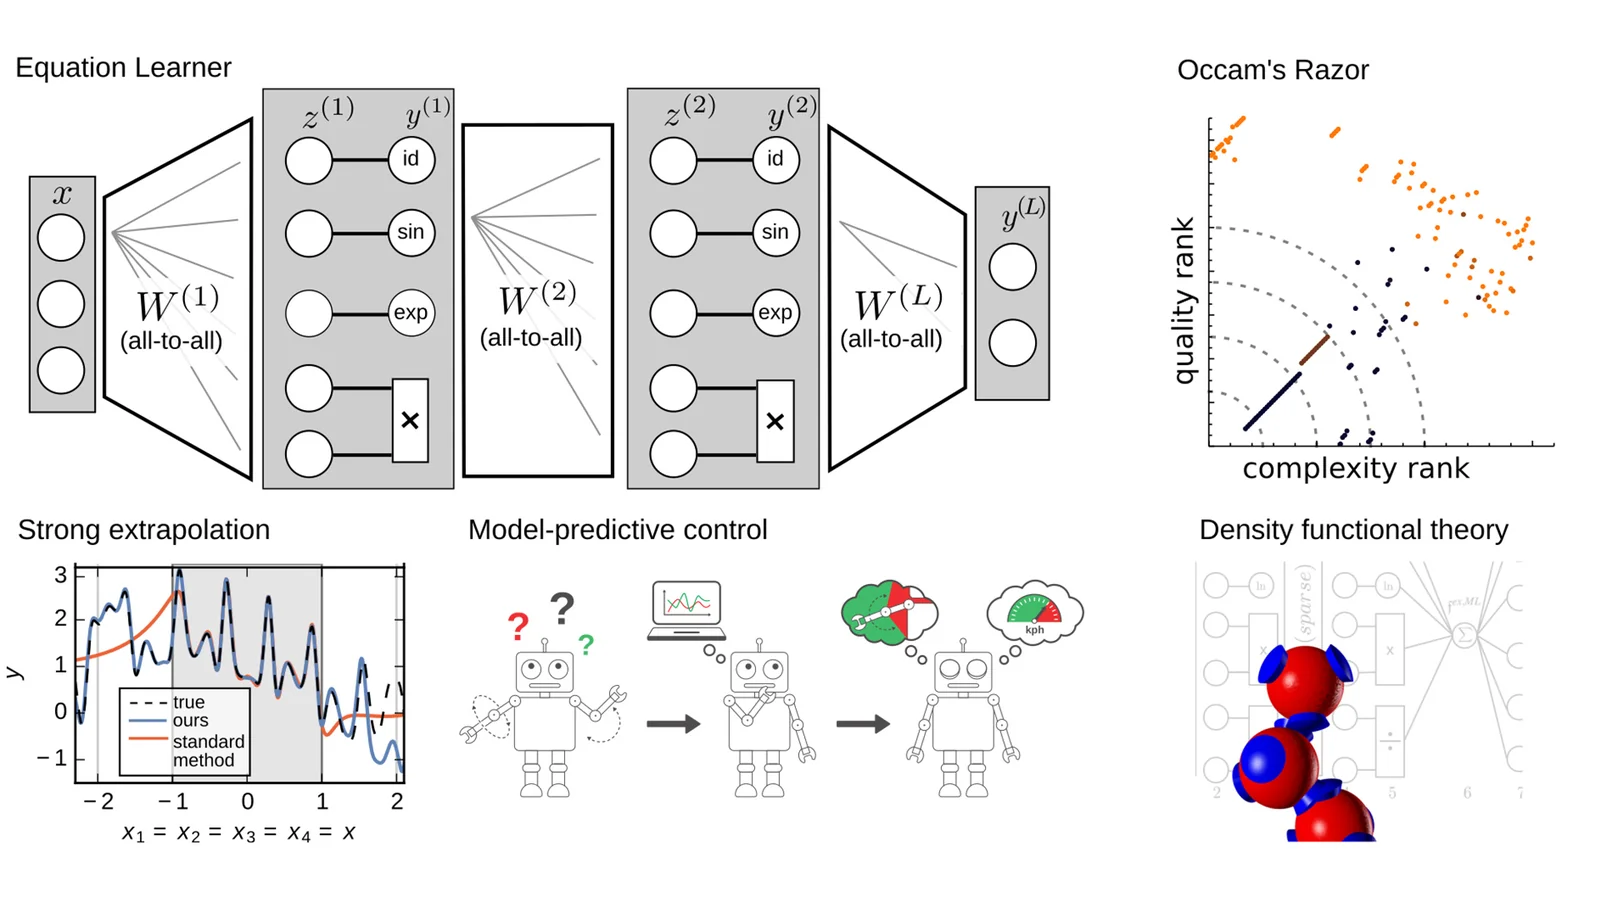
Uncertainty in Equation Learning
Proceedings of the Genetic and Evolutionary Computation Conference Companion (GECCO)
·
2022
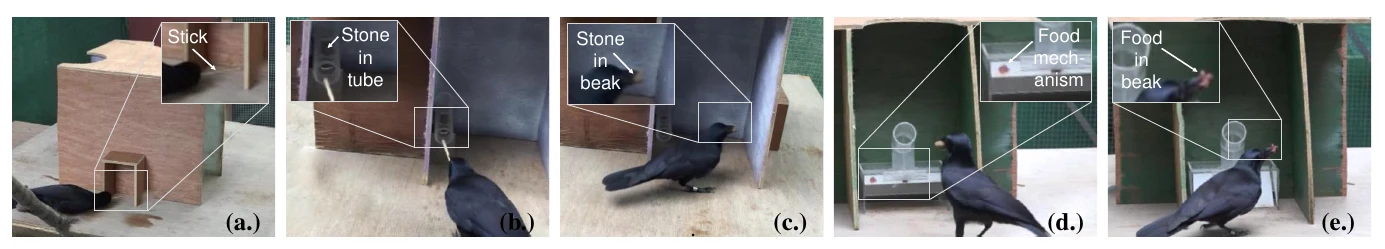
Intelligent problem-solving as integrated hierarchical reinforcement learning
Nature Machine Intelligence
·
2022
2021
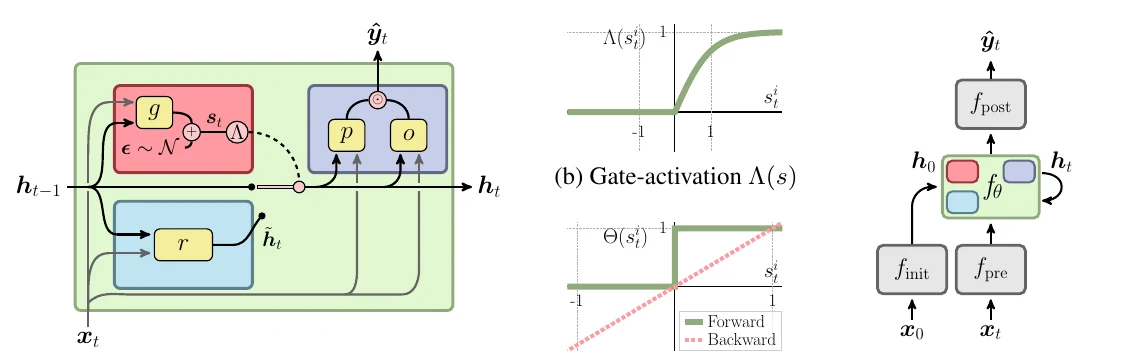
Sparsely Changing Latent States for Prediction and Planning in Partially Observable Domains
Advances in Neural Information Processing Systems (NeurIPS 2021)
·
2021
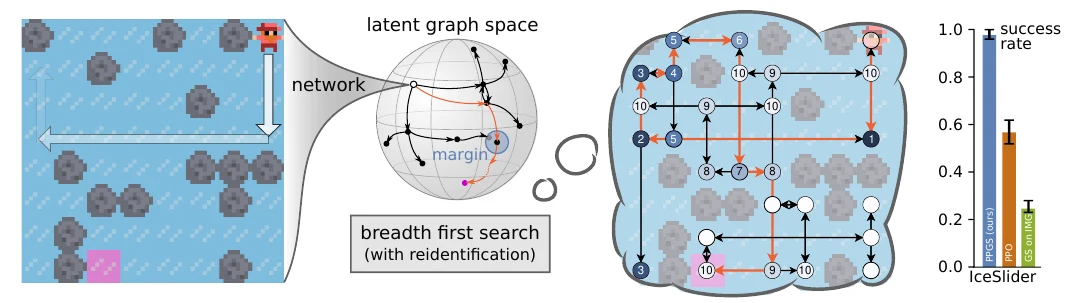
Planning from Pixels in Environments with Combinatorially Hard Search Spaces
Advances in Neural Information Processing Systems (NeurIPS 2021)
·
2021
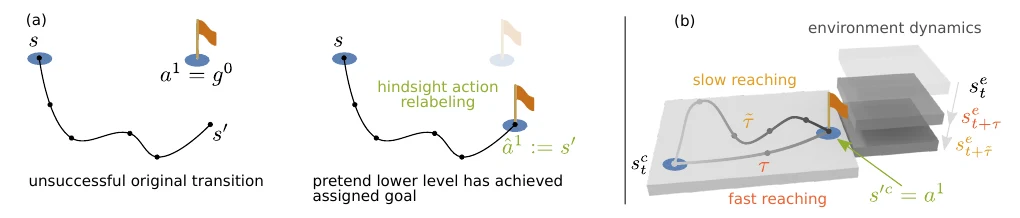
Hierarchical Reinforcement Learning with Timed Subgoals
Advances in Neural Information Processing Systems 34 (NeurIPS 2021)
·
2021
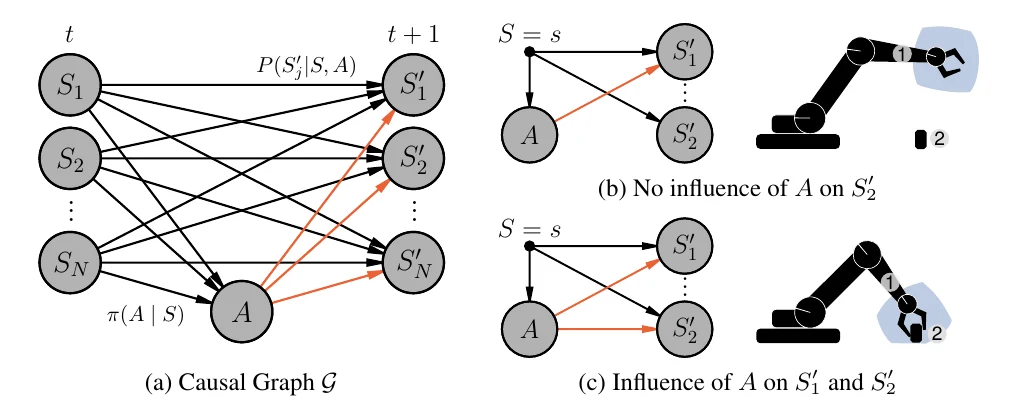
Causal Influence Detection for Improving Efficiency in Reinforcement Learning
Advances in Neural Information Processing Systems 34 (NeurIPS 2021)
·
2021
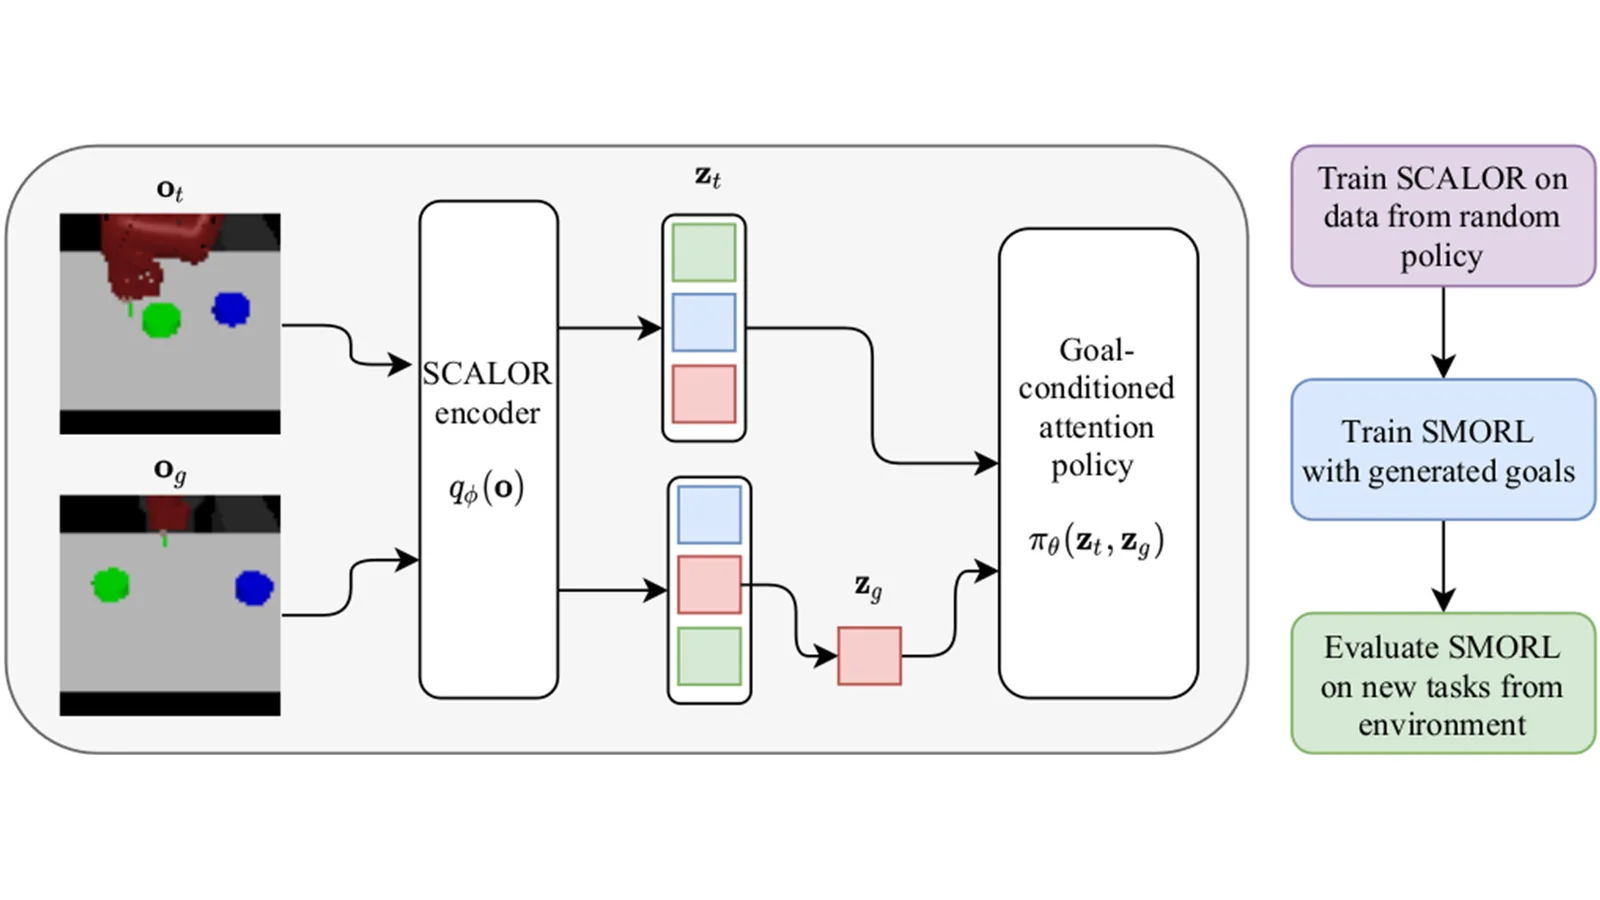
Self-supervised Reinforcement Learning with Independently Controllable Subgoals
Conference on Robot Learning
·
2021
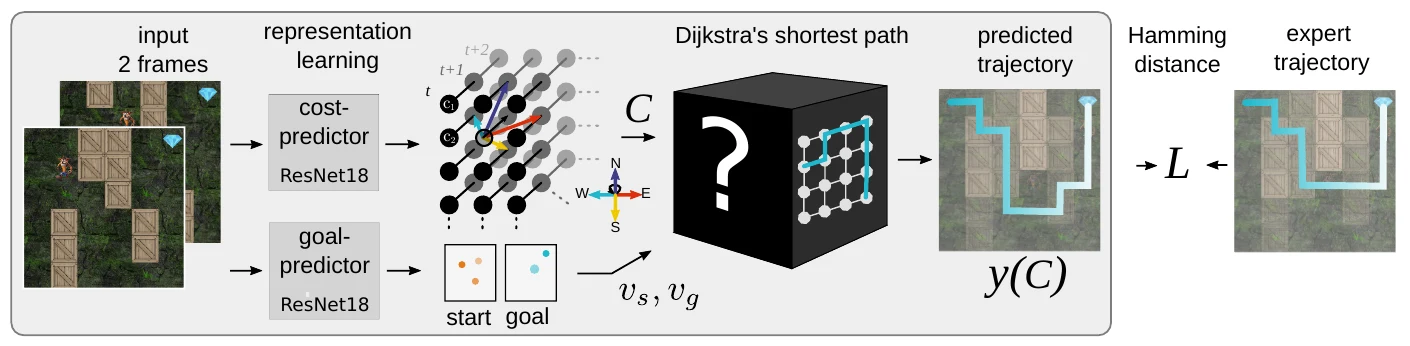
Neuro-algorithmic Policies Enable Fast Combinatorial Generalization
Proceedings of the 2021 International Conference on Machine Learning (ICML)
·
2021
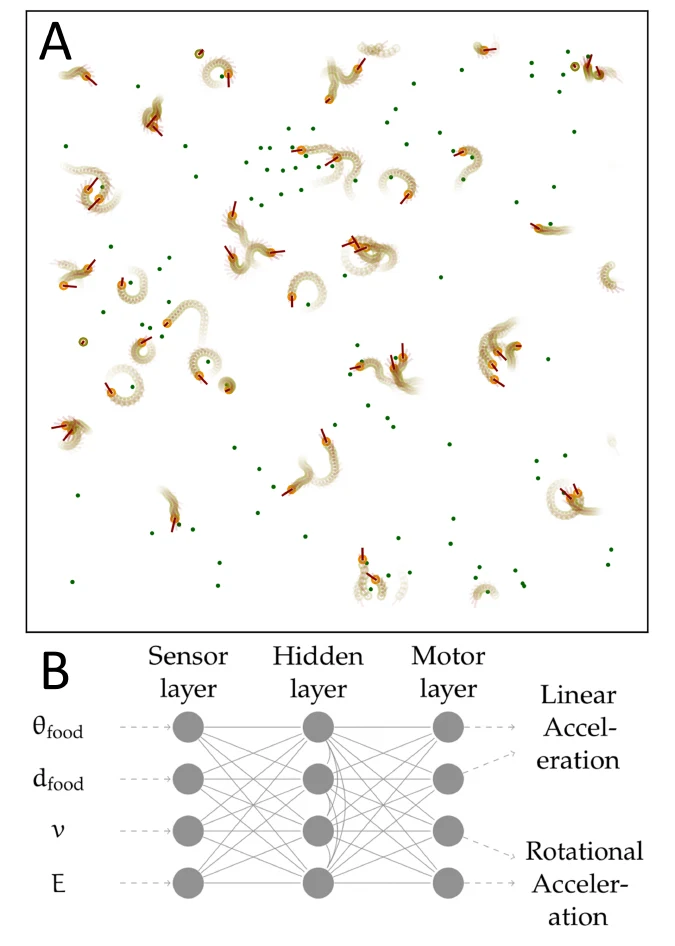
The dynamical regime and its importance for evolvability, task performance and generalization
The 2021 Conference on Artificial Life
·
2021
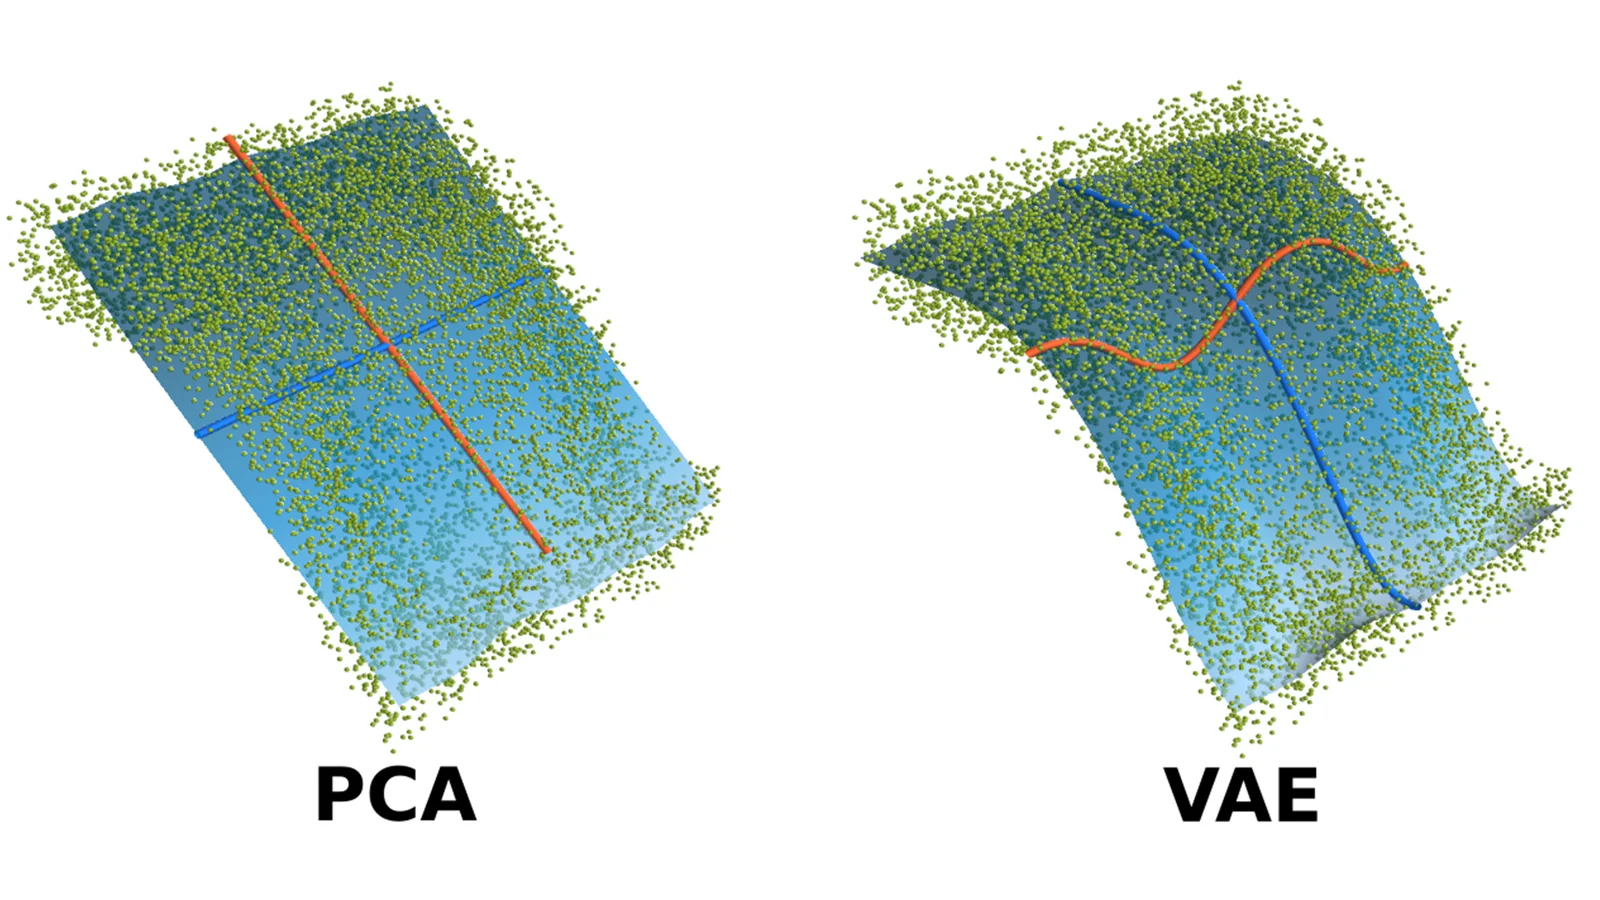
Demystifying Inductive Biases for (Beta-)VAE Based Architectures
Proceedings of the 2021 International Conference on Machine Learning (ICML)
·
2021
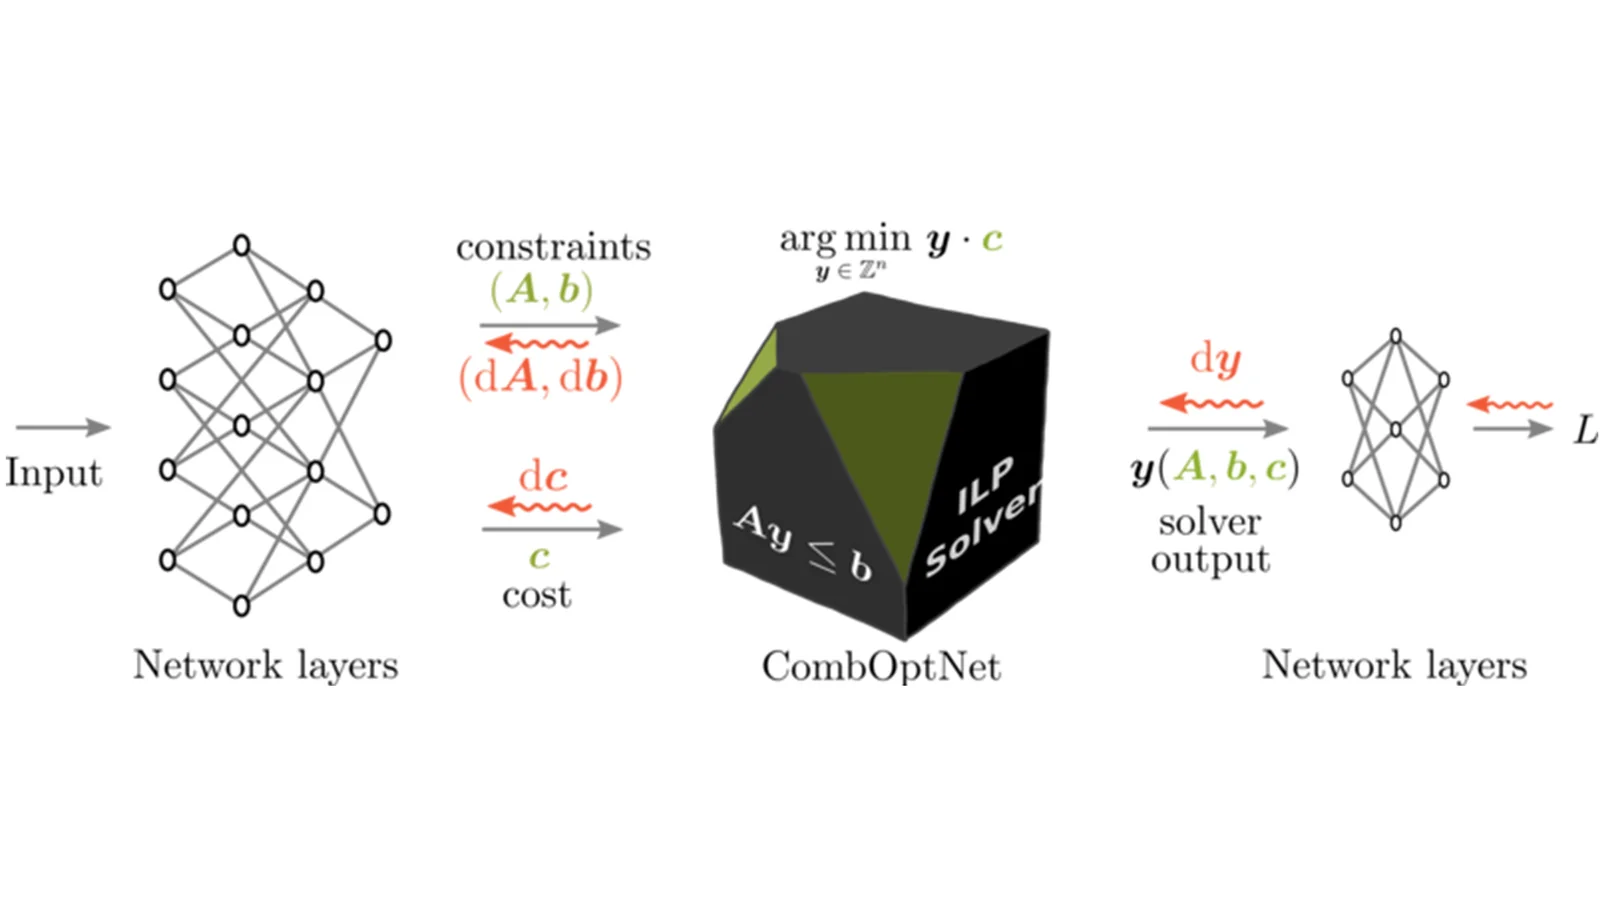
CombOptNet: Fit the Right NP-Hard Problem by Learning Integer Programming Constraints
Proceedings of the 38th International Conference on Machine Learning
·
2021
How to Train Your Differentiable Filter
Autonomous Robots
·
2021
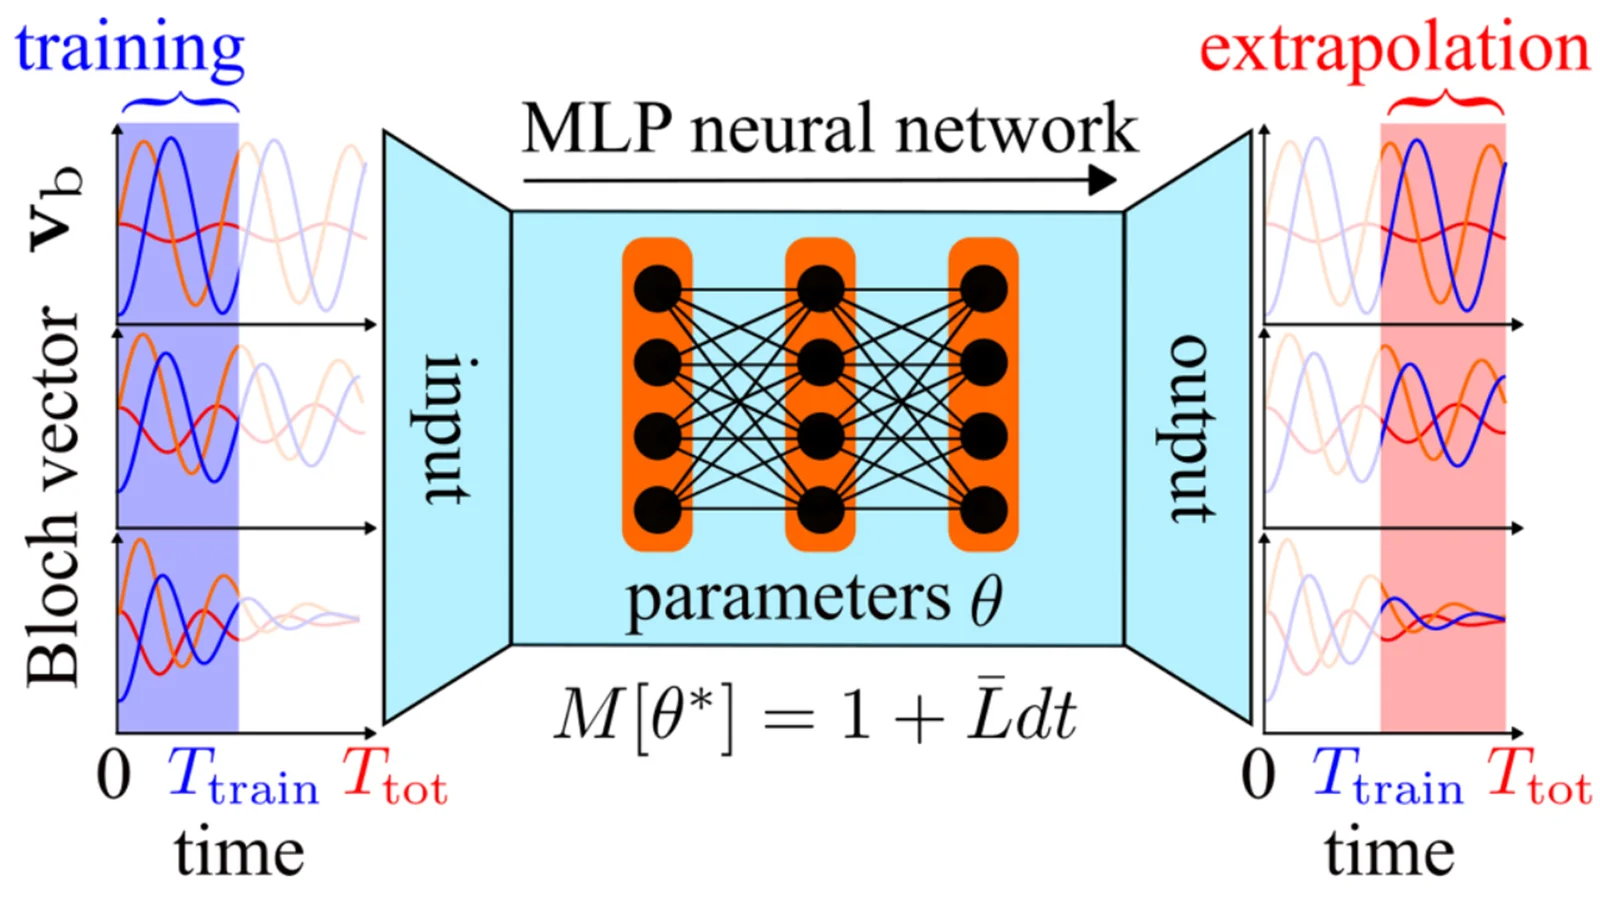
Machine learning time-local generators of open quantum dynamics
Phys. Rev. Research
·
2021
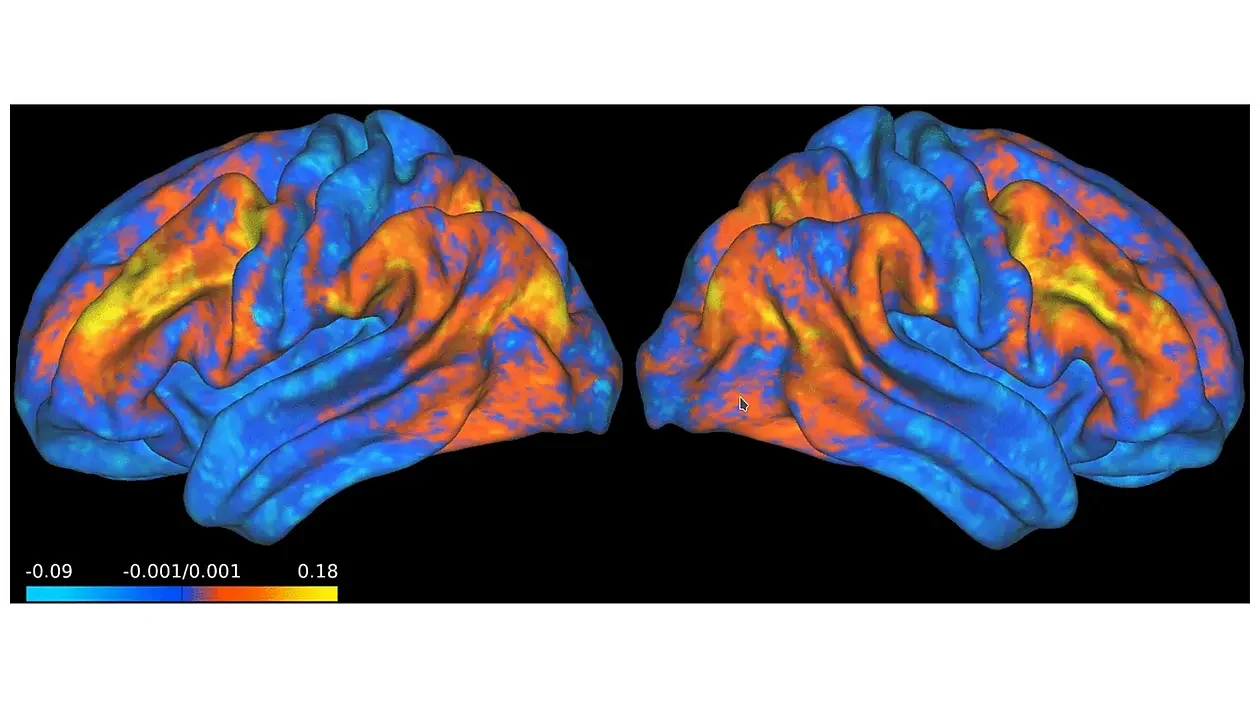
Jumping over baselines with new methods to predict activation maps from resting-state fMRI
Scientific Reports
·
2021
Self-supervised Visual Reinforcement Learning with Object-centric Representations
International Conference on Learning Representations
·
2021
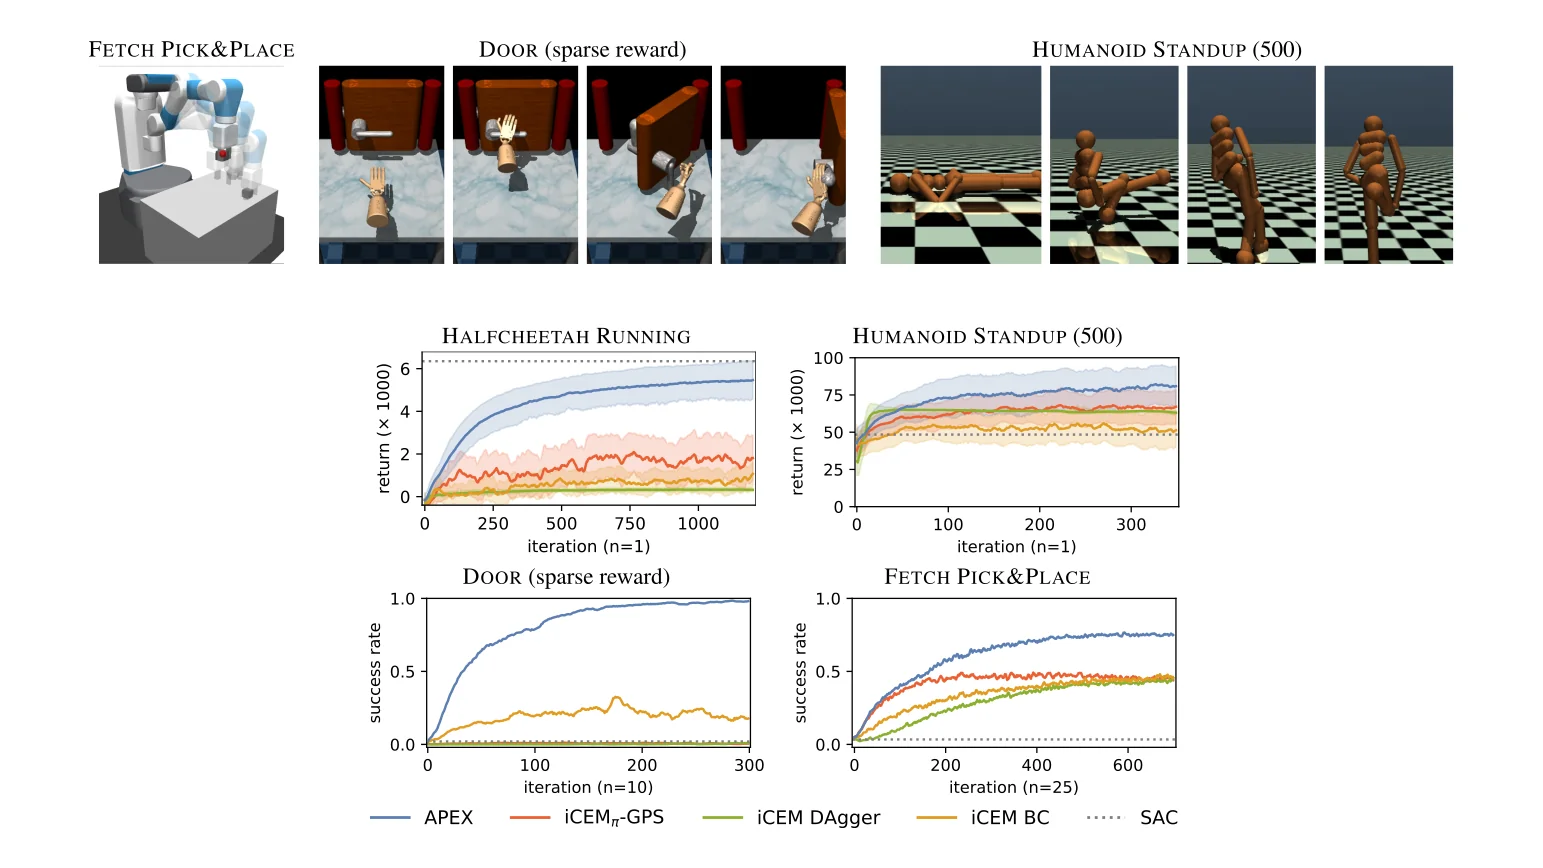
Extracting Strong Policies for Robotics Tasks from Zero-order Trajectory Optimizers
International Conference on Learning Representations
·
2021
Informed Equation Learning
arXiv
·
2021
2020
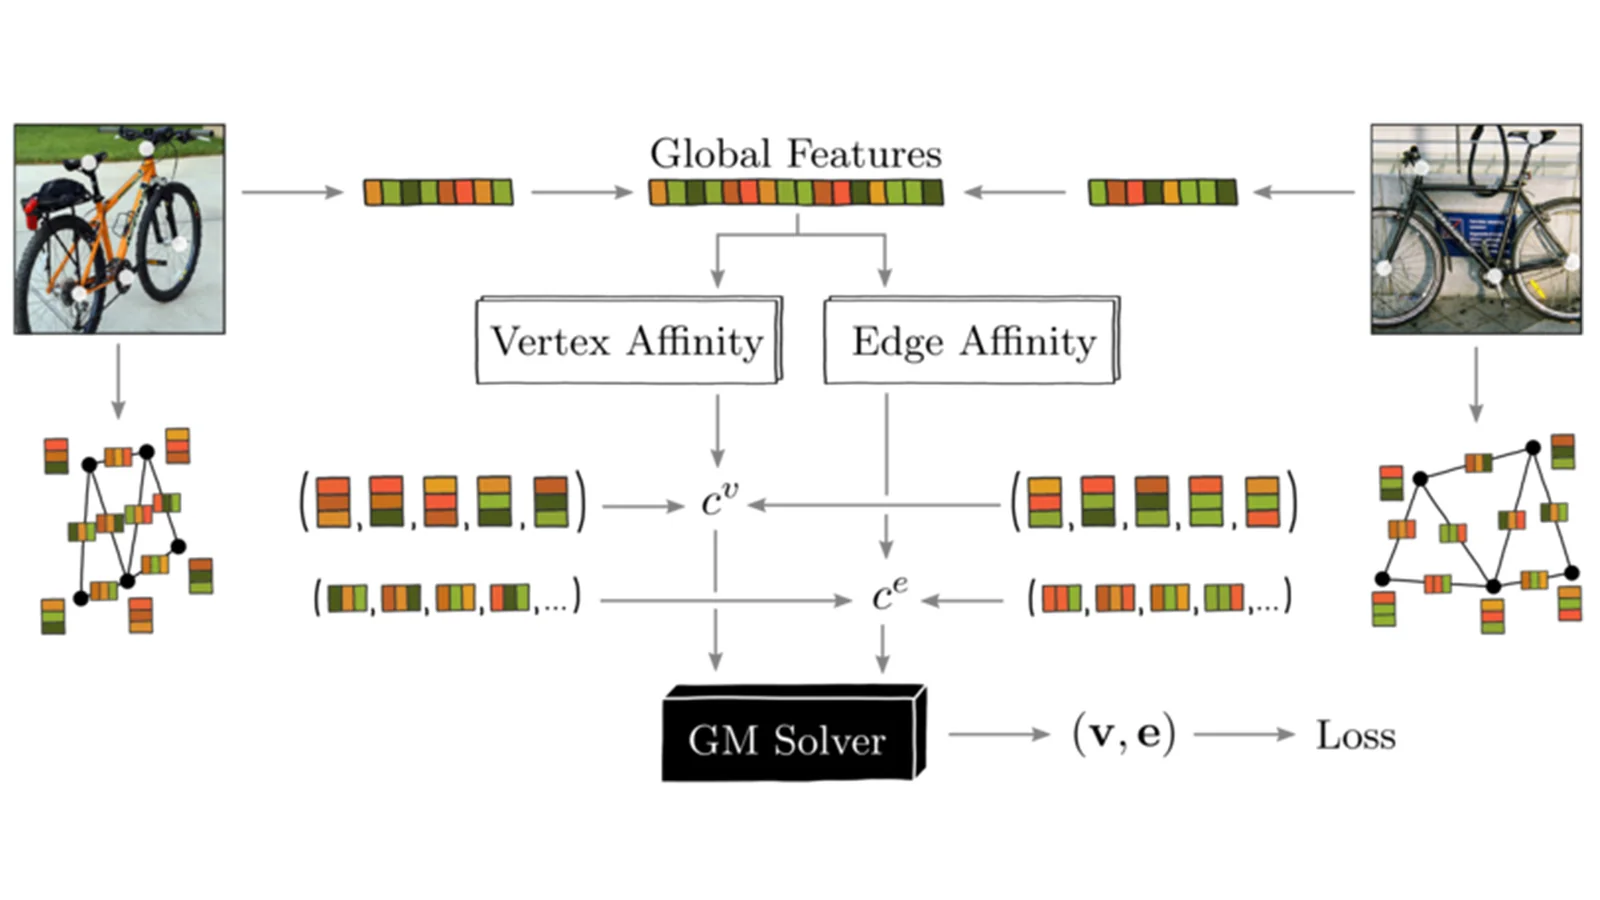
Deep Graph Matching via Blackbox Differentiation of Combinatorial Solvers
Computer Vision – ECCV 2020
·
2020
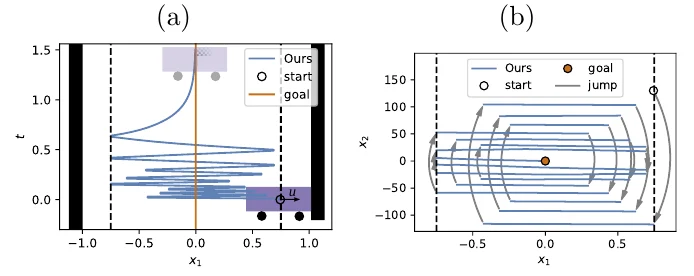
Fast Non-Parametric Learning to Accelerate Mixed-Integer Programming for Online Hybrid Model Predictive Control
21rst IFAC World Congress
·
2020
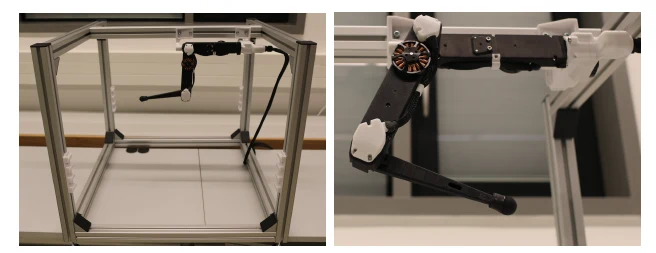
A Real-Robot Dataset for Assessing Transferability of Learned Dynamics Models
IEEE International Conference on Robotics and Automation (ICRA)
·
2020
Analytical classical density functionals from an equation learning network
The Journal of Chemical Physics
·
2020
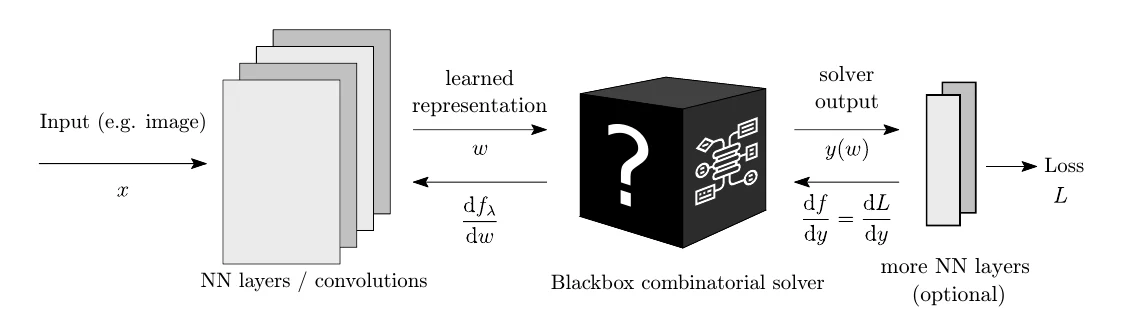
Differentiation of blackbox combinatorial solvers
International Conference on Learning Representations
·
2020
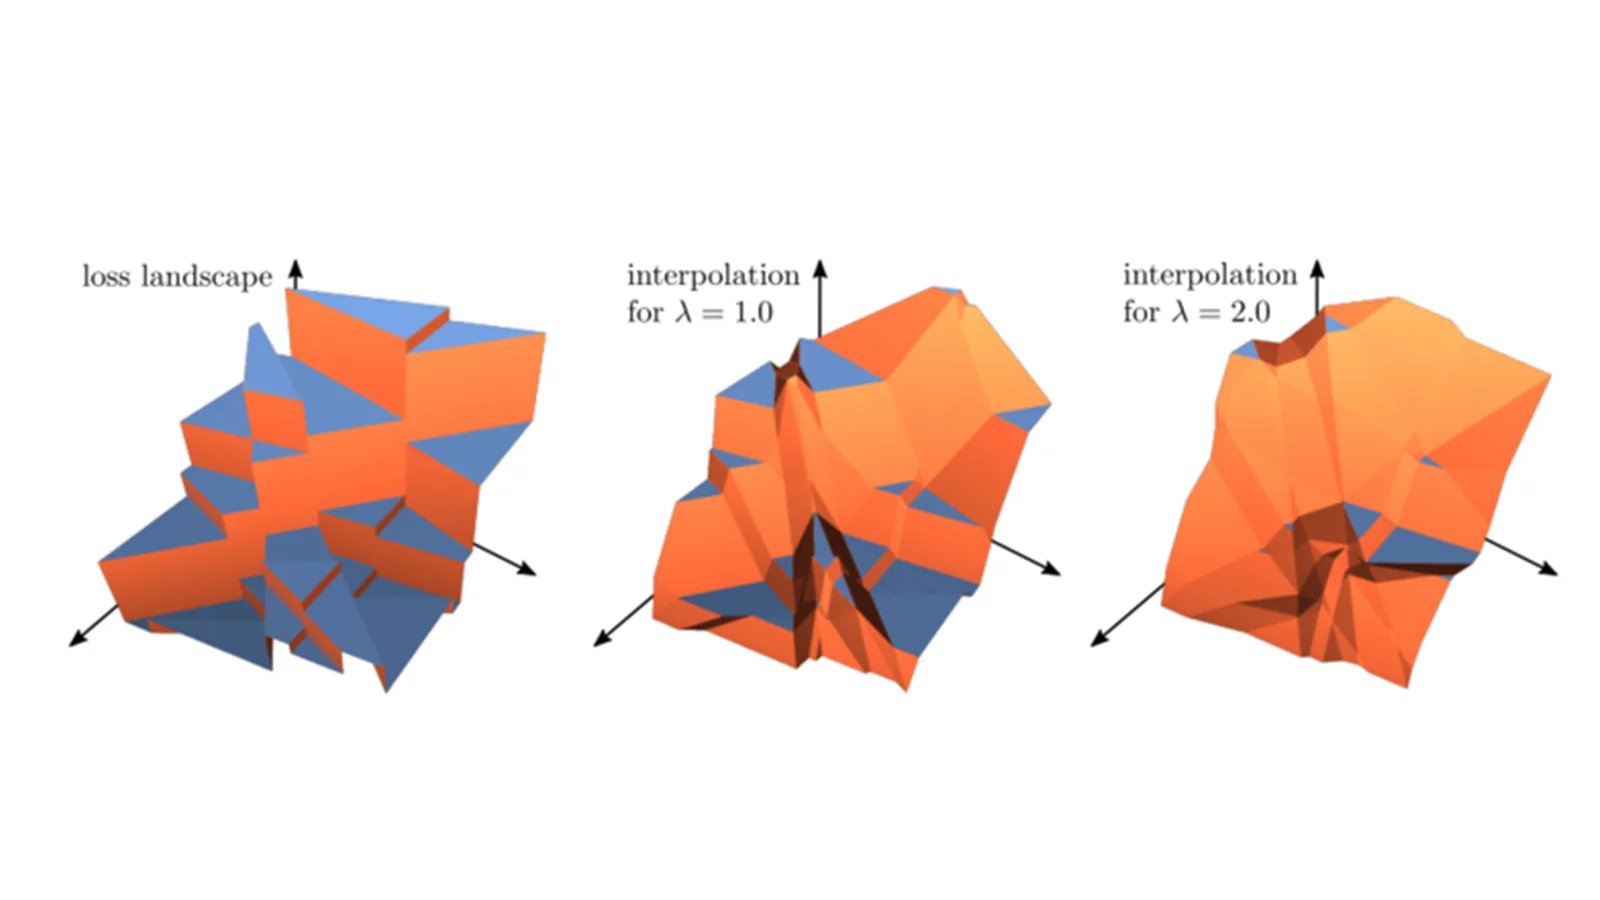
Optimizing Rank-based Metrics with Blackbox Differentiation
Conference on Computer Vision and Pattern Recognition
·
2020
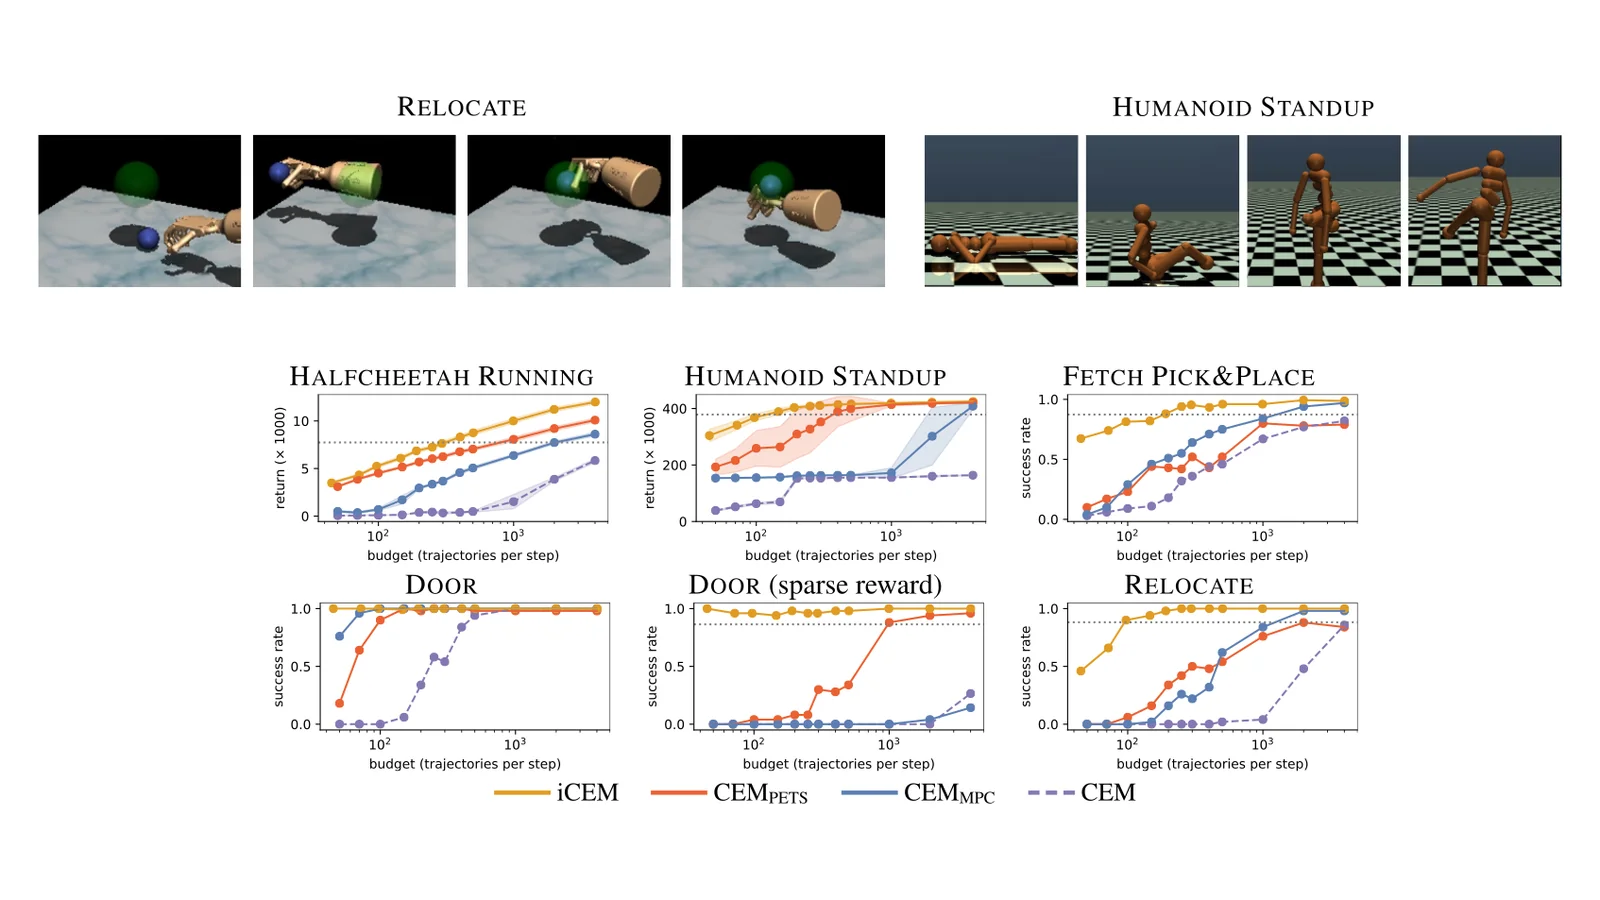
Sample-efficient Cross-Entropy Method for Real-time Planning
Conference on Robot Learning (CoRL) 2020
·
2020
2019
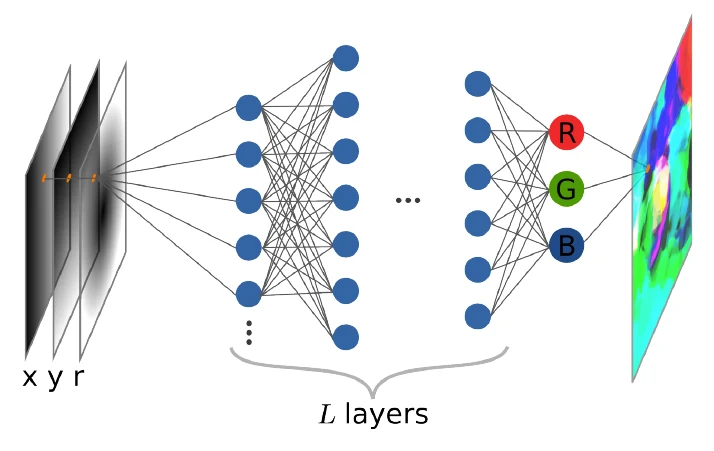
Assessing Aesthetics of Generated Abstract Images Using Correlation Structure
Proceedings 2019 IEEE Symposium Series on Computational Intelligence (SSCI)
·
2019
Variational Autoencoders Pursue PCA Directions (by Accident)
Conference on Computer Vision and Pattern Recognition (CVPR'19)
·
2019
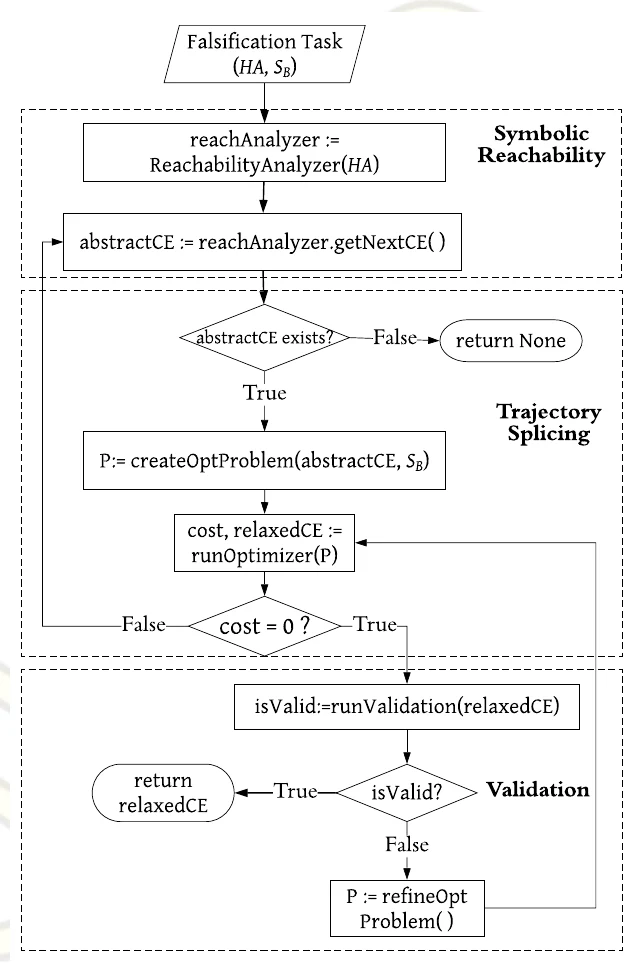
Falsification of Hybrid Systems using Symbolic Reachability and Trajectory Splicing
22nd ACM Intl. Conf. on Hybrid Systems: Computation and Control (HSCC 2019)
·
2019
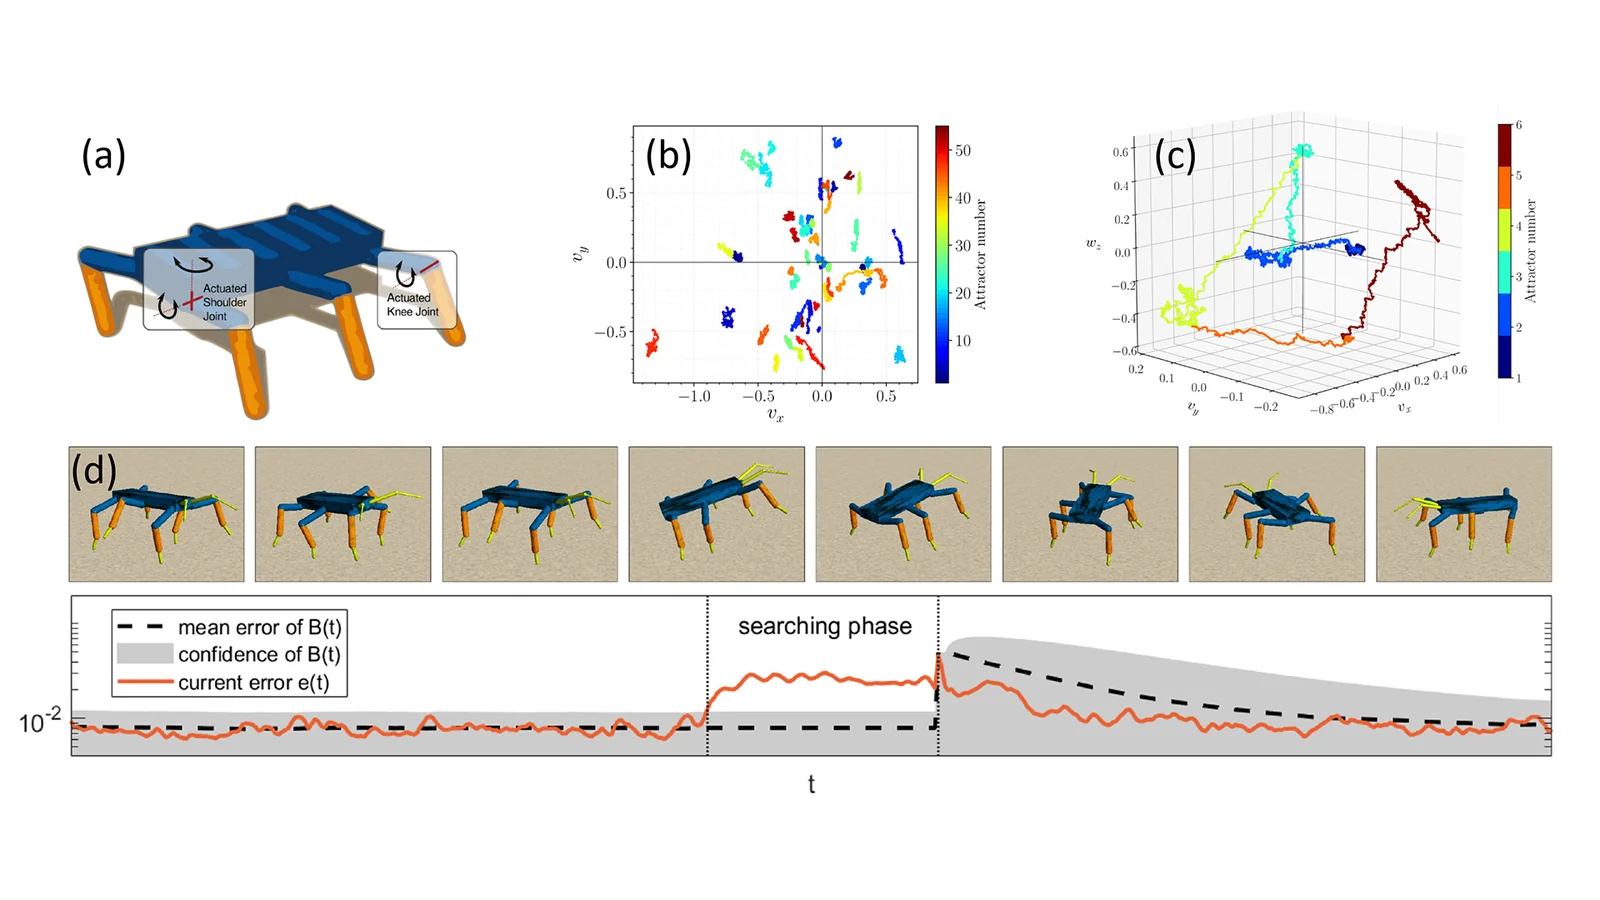
Autonomous Identification and Goal-Directed Invocation of Event-Predictive Behavioral Primitives
IEEE Transactions on Cognitive and Developmental Systems
·
2019
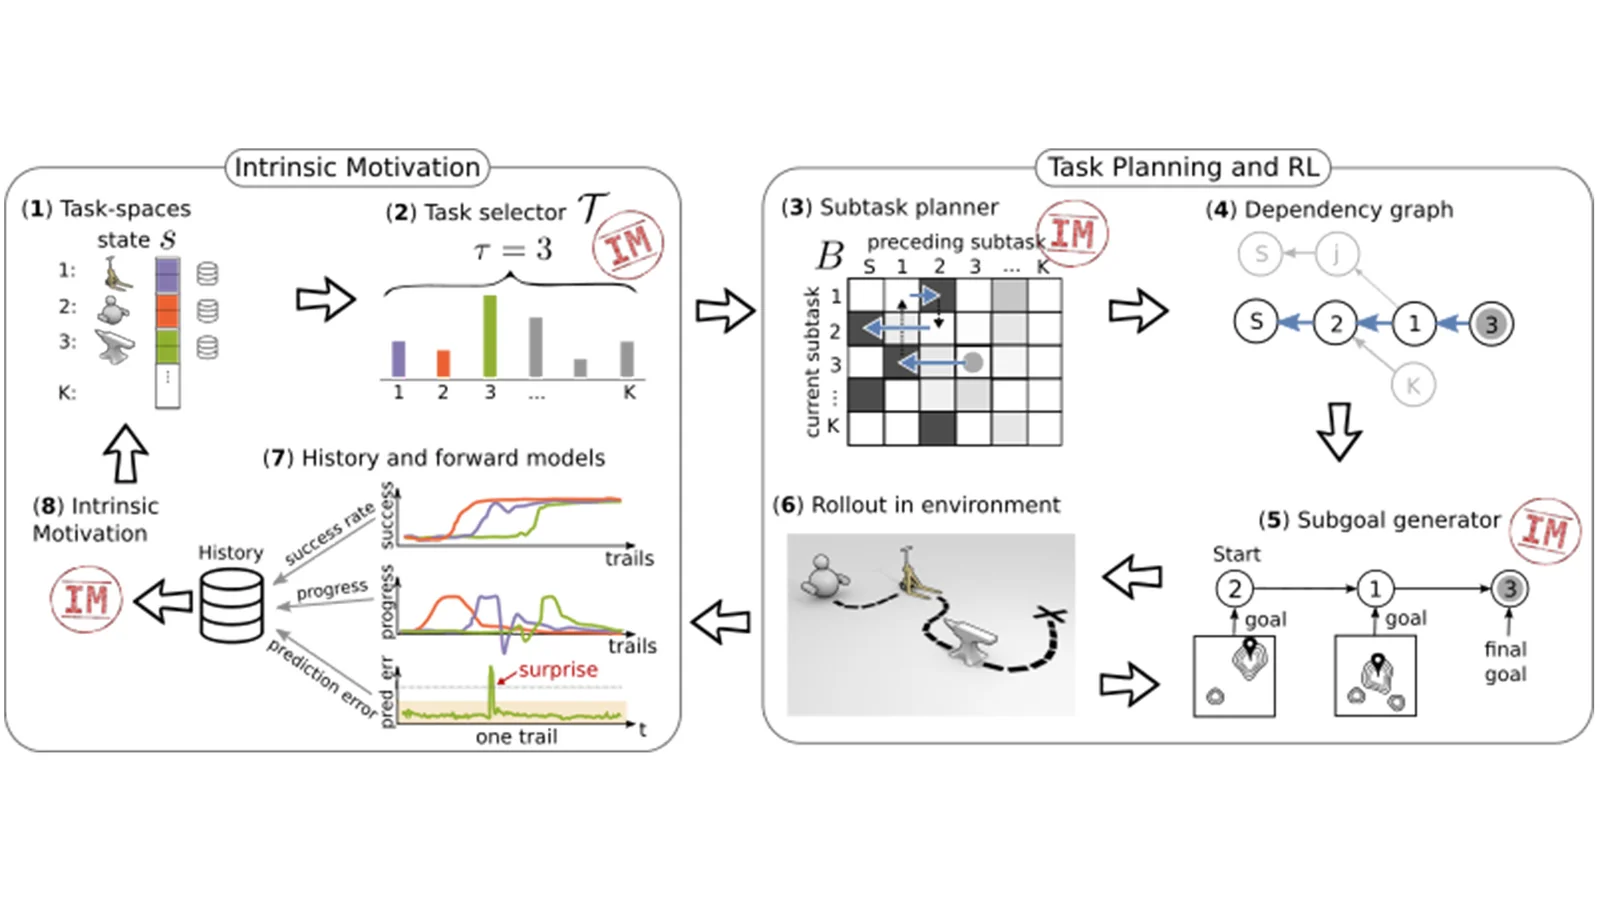
Control What You Can: Intrinsically Motivated Task-Planning Agent
Advances in Neural Information Processing (NeurIPS'19)
·
2019
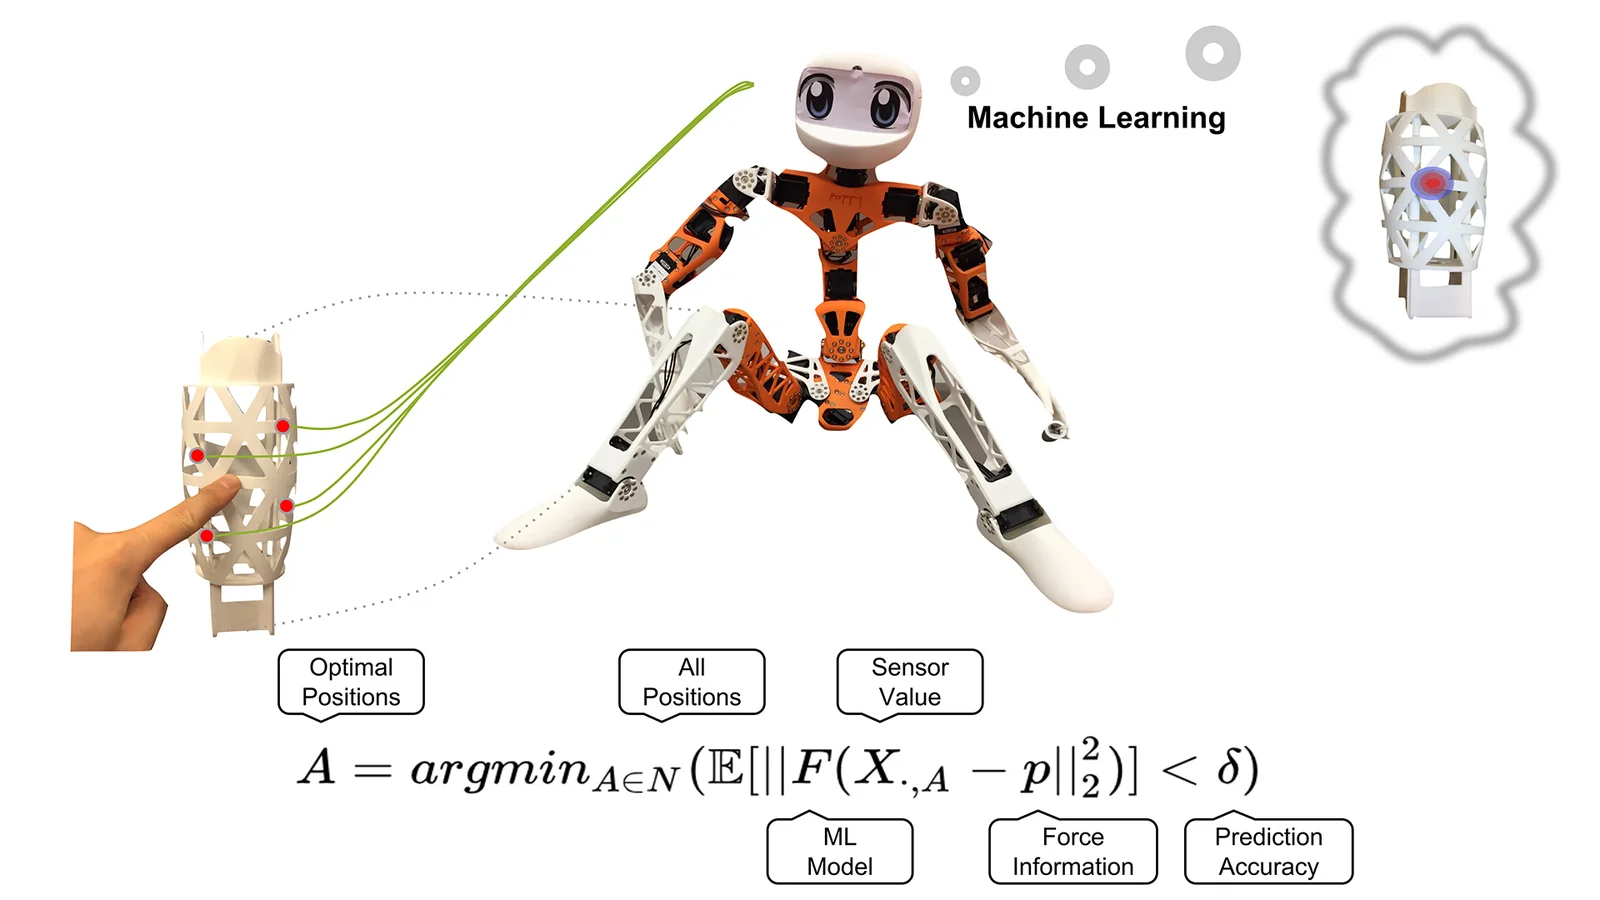
Machine Learning for Haptics: Inferring Multi-Contact Stimulation From Sparse Sensor Configuration
Frontiers in Neurorobotics
·
2019
2018
Nonlinear decoding of a complex movie from the mammalian retina
PLOS Computational Biology
·
2018
Learning equations for extrapolation and control
Proc. 35th International Conference on Machine Learning, ICML 2018, Stockholm, Sweden
·
2018
Systematic self-exploration of behaviors for robots in a dynamical systems framework
Proc. Artificial Life XI
·
2018
Robust and Cheap 3D Haptic Sensation using Deformation Patterns and Machine Learning
IEEE-RAS International Conference on Humanoid Robots (Humanoids 2018)
·
2018
Robust Affordable 3D Haptic Sensation via Learning Deformation Patterns
Proceedings International Conference on Humanoid Robots (IEEE Humanoids)
·
2018
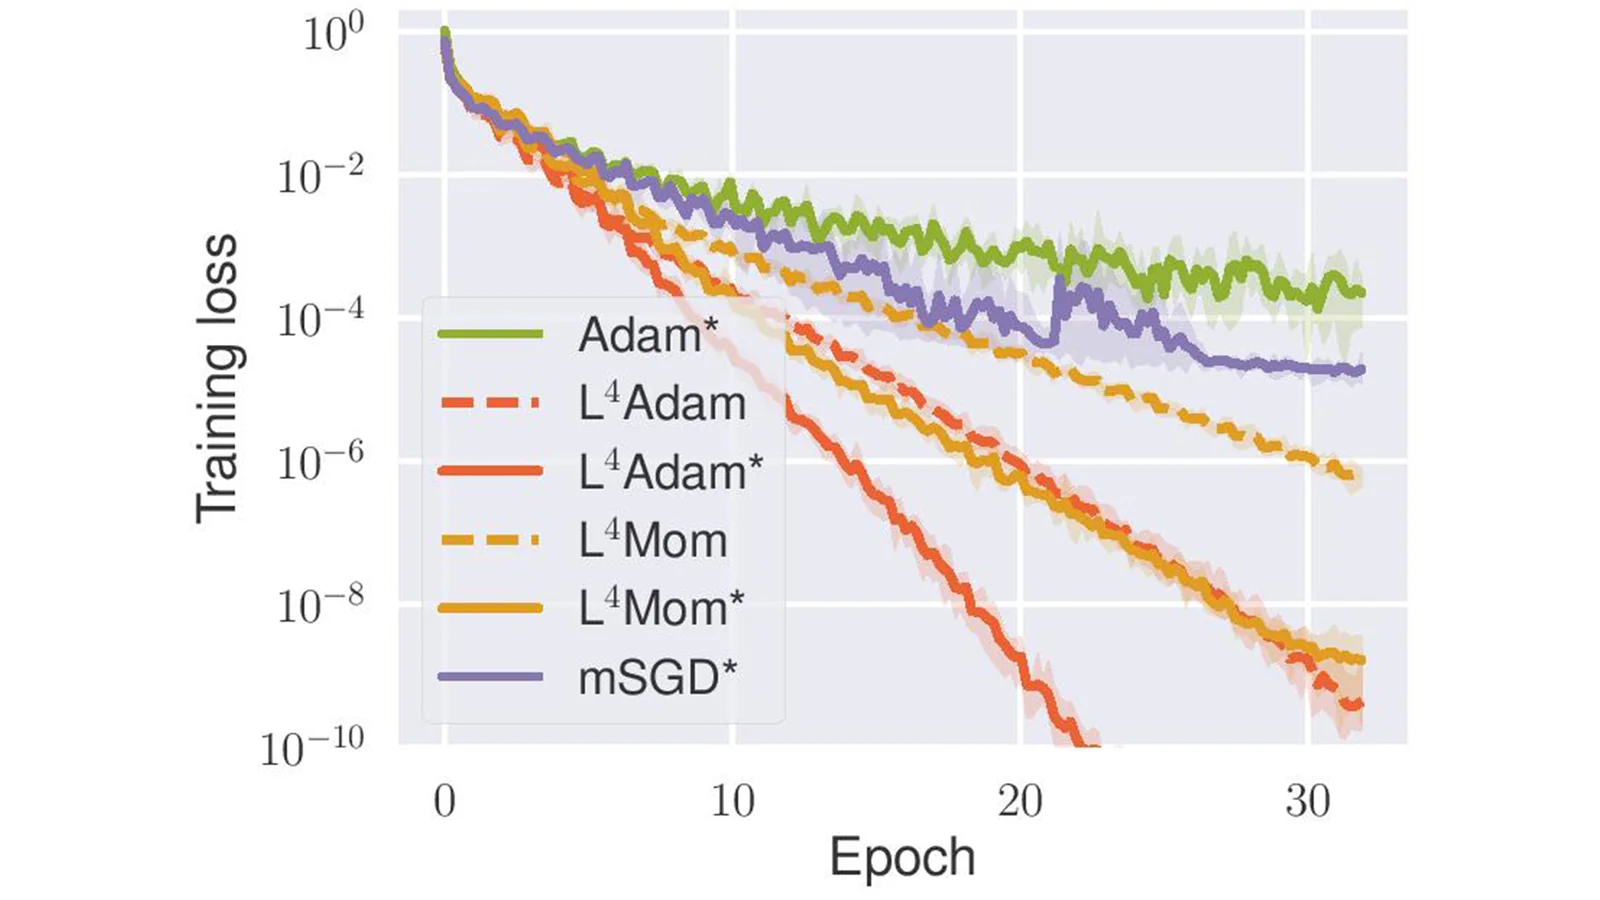
L4: Practical loss-based stepsize adaptation for deep learning
Advances in Neural Information Processing (NeurIPS'18)
·
2018
Deep Reinforcement Learning for Event-Triggered Control
2018 IEEE Conference on Decision and Control (CDC)
·
2018
2017
Self-Organized Behavior Generation for Musculoskeletal Robots
Frontiers in Neurorobotics
·
2017
2016
Dynamical self-consistency leads to behavioral development and emergent social interactions in robots
2016 Joint IEEE International Conference on Development and Learning and Epigenetic Robotics (ICDL-EpiRob)
·
2016
Compliant control for soft robots: emergent behavior of a tendon driven anthropomorphic arm.
2016 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
·
2016
Extrapolation and learning equations
arXiv preprint
·
2016
2015
Quantifying Emergent Behavior of Autonomous Robots
Entropy
·
2015
Novel plasticity rule can explain the development of sensorimotor intelligence
Proceedings of the National Academy of Sciences
·
2015
2014
Self-Exploration of the Stumpy Robot with Predictive Information Maximization
Proc. From Animals to Animats, SAB 2014
·
2014
Robot Learning by Guided Self-Organization
Guided Self-Organization: Inception
·
2014
2013
Robustness of guided self-organization against sensorimotor disruptions
Advances in Complex Systems
·
2013
Behavior as broken symmetry in embodied self-organizing robots
Advances in Artificial Life, ECAL 2013
·
2013
2012
Predictive information in reinforcement learning of embodied agents
Int. Workshop on Guided Self-Organization 5
·
2012
Variants of guided self-organization for robot control
Theory in Biosci.
·
2012
2011
Tipping the Scales: Guidance and Intrinsically Motivated Behavior
Advances in Artificial Life, ECAL 2011
·
2011
2010
LpzRobots: A free and powerful robot simulator
<http://robot.informatik.uni-leipzig.de/software>
·
2010
Taming the Beast: Guided Self-organization of Behavior in Autonomous Robots
From Animals to Animats 11
·
2010
Goal-Oriented Control of Self-Organizing Behavior in Autonomous Robots
Georg-August-Universität Göttingen
·
2010
Playful Machines: Tutorial
<http://robot.informatik.uni-leipzig.de/tutorial?lang=en>
·
2010
2009
2008
Emergence of Interaction Among Adaptive Agents
Proc. From Animals to Animats 10 (SAB 2008)
·
2008
Structure from Behavior in Autonomous Agents
Proc. IEEE Intl. Conf. Intelligent Robots and Systems (IROS 2008)
·
2008
2007
Guided Self-organisation for Autonomous Robot Development
Advances in Artificial Life 9th European Conference, ECAL 2007
·
2007
2006
Let It Roll – Emerging Sensorimotor Coordination in a Spherical Robot
Proc, Artificial Life X
·
2006
Rocking Stamper and Jumping Snake from a Dynamical System Approach to Artificial Life
Adaptive Behavior
·
2006
From Motor Babbling to Purposive Actions: Emerging Self-exploration in a Dynamical Systems Approach to Early Robot Development
Proc. From Animals to Animats 9, SAB 2006
·
2006
2005
Learning to Feel the Physics of a Body
Computational Intelligence for Modelling, Control and Automation, CIMCA 2005
·
2005